Research Overview

My research focuses on developing interactive and trustworthy intelligent systems that operate within complex physical environments. These systems aim to enable safe and coordinated interactions among humans, infrastructure, and autonomous agents, supporting the next generation of intelligent mobility and infrastructure systems.

My research specifically involves:

1) Connected and Automated Mobility Intelligence: modeling interactions among vehicles, infrastructure, and humans, and developing AI methods for safe motion prediction, planning, and control within connected vehicle–road–cloud and V2X systems.
2) Digital Twin and Cyber-Physical Systems: building end-to-end digital twin pipelines that integrate data, simulation, and system optimization, while leveraging generative AI and LLM-based reasoning to synthesize scenarios and agent behaviors.
3) Spatiotemporal AI for Networked Systems: developing methods for spatiotemporal reconstruction, forecasting, and scalable spatial–temporal network analysis to enable data fusion and system understanding across large-scale dynamic networks.

My research integrates methods from machine learning, generative AI, network science, and computational optimization with domain knowledge in transportation engineering and cyber-physical systems. Through this interdisciplinary approach, I aim to develop intelligent infrastructure and mobility systems that improve transportation safety, efficiency, and everyday human mobility.

Overview of Keshu Wu's research: connected and automated mobility intelligence, digital twins and cyber-physical systems, and spatiotemporal AI for networked systems.

Publications

Filter by keyword Showing all 21 publications

Autonomous Mobility Intelligence

Higher-order multi-agent interaction modeling and relational reasoning; Multimodal motion prediction, planning, and control; Safety-critical decision-making and mixed-traffic intelligence.

arXiv

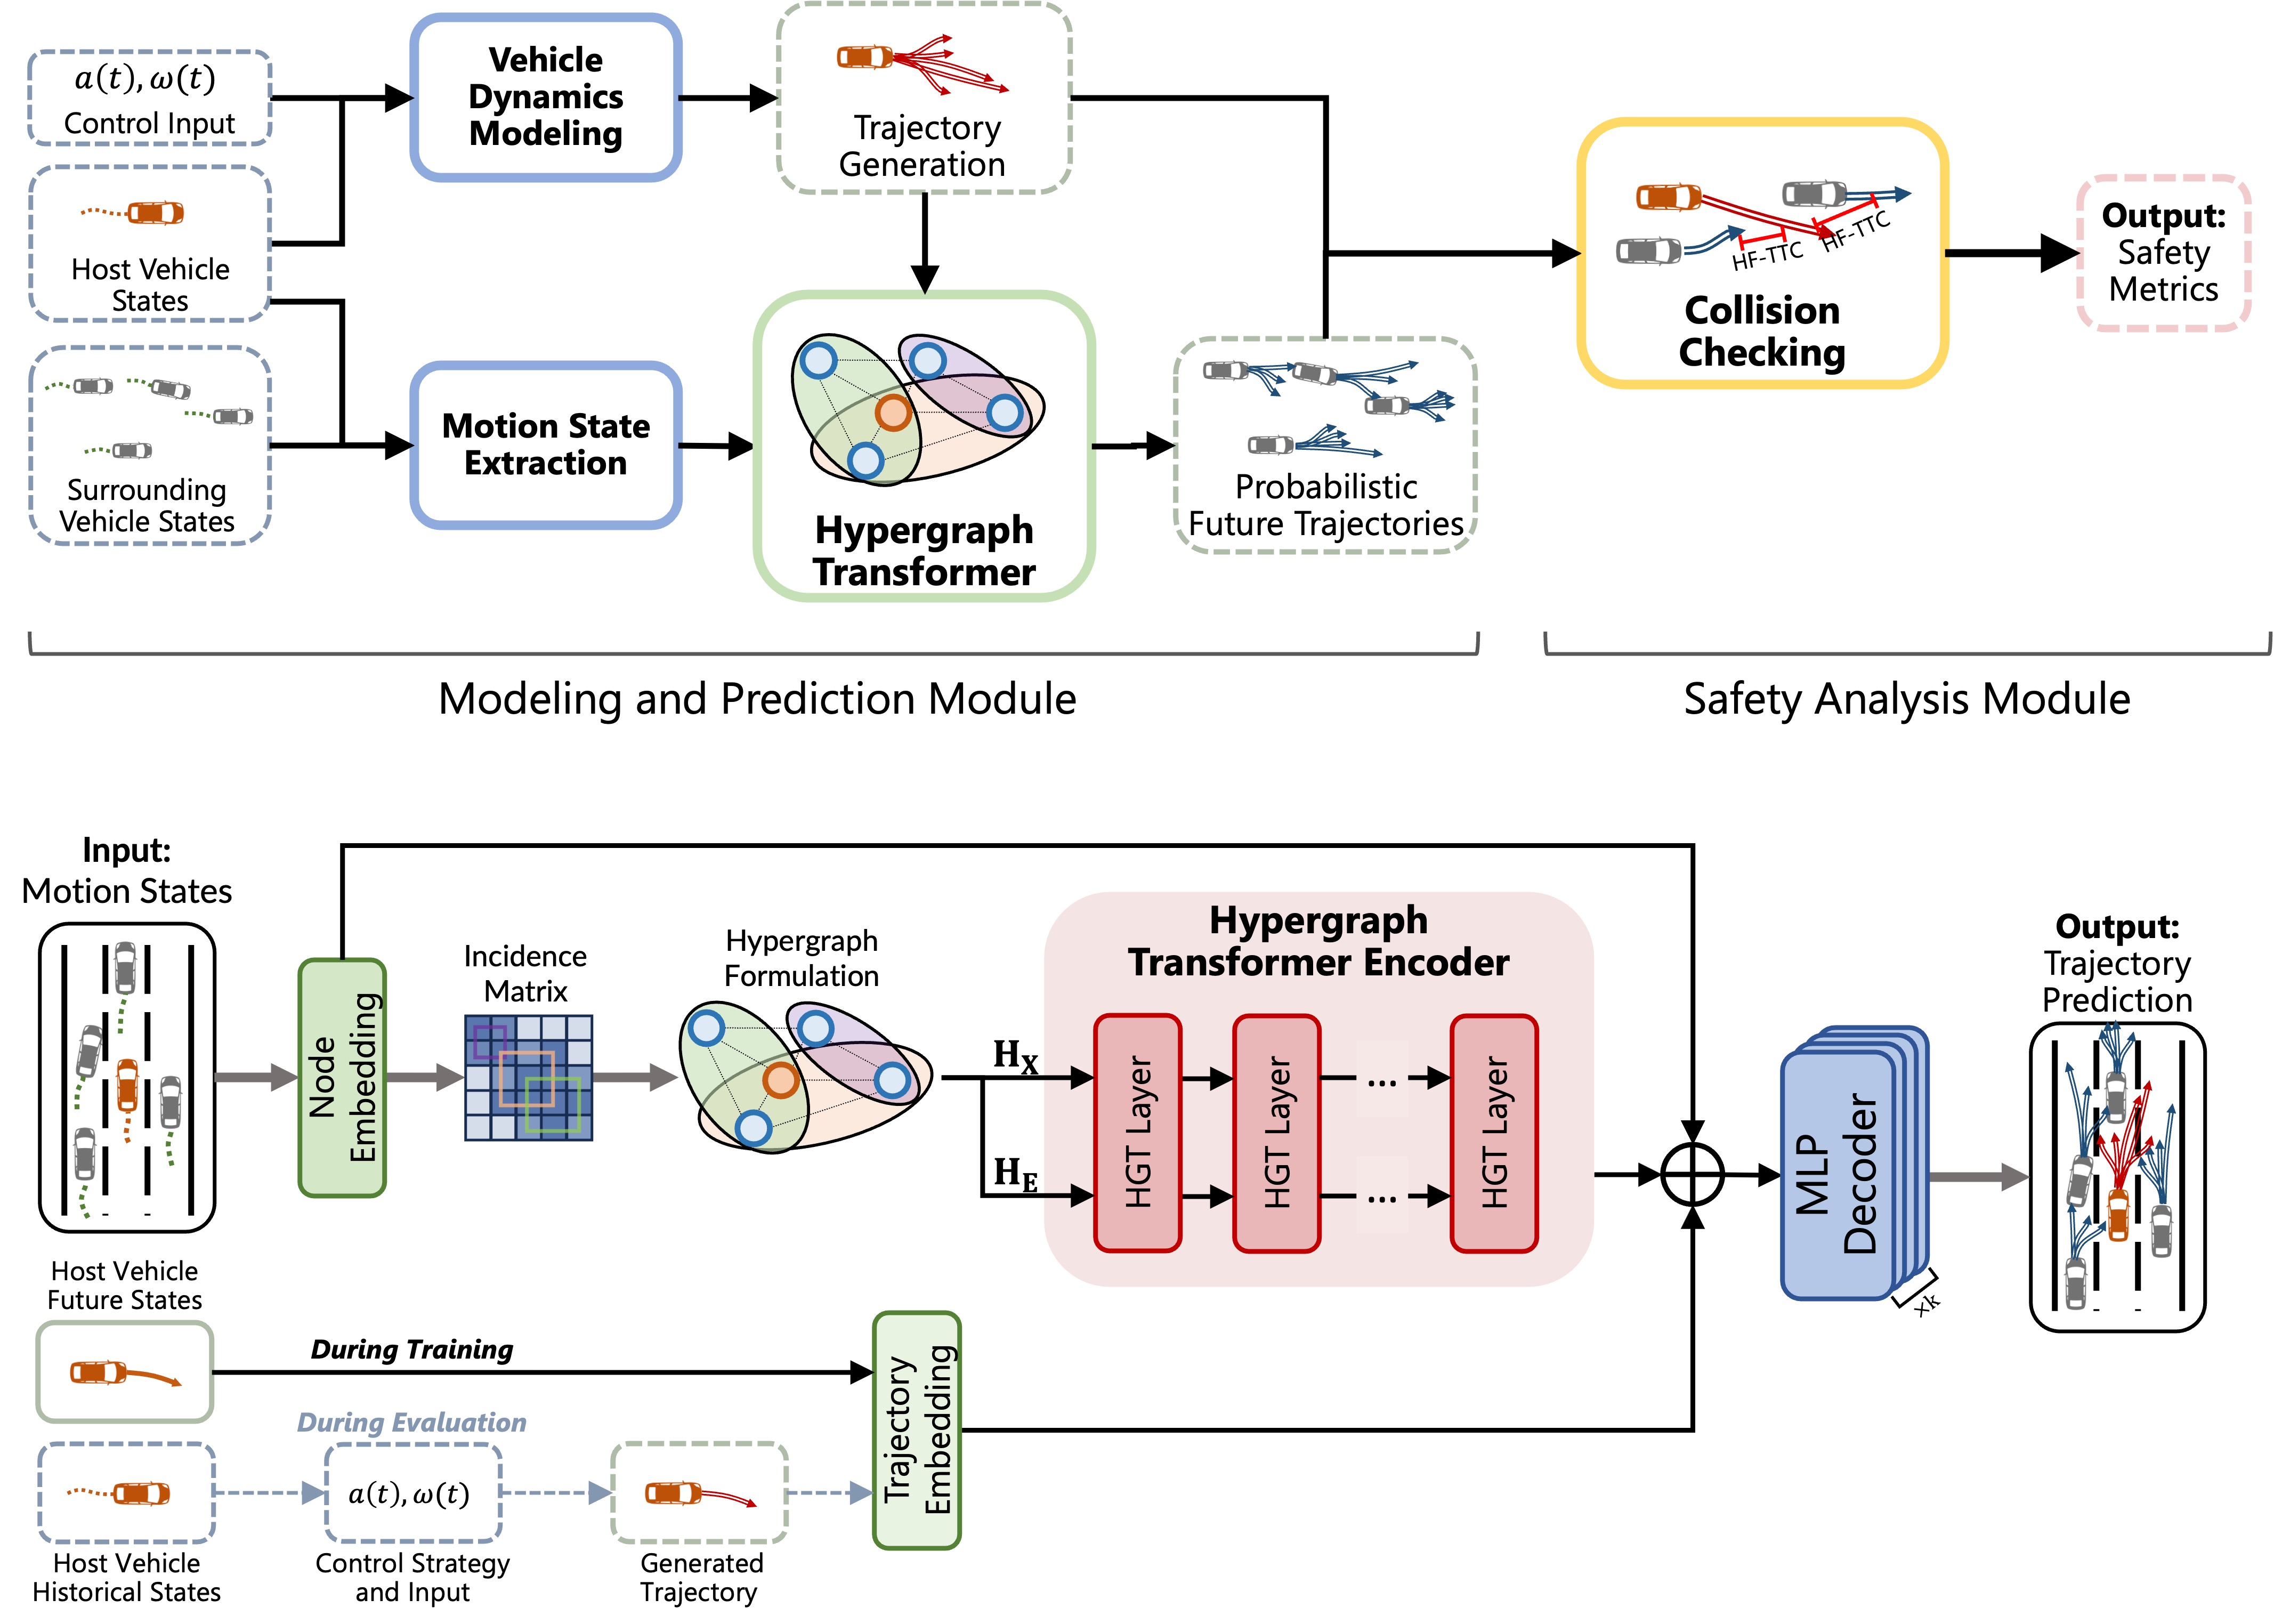
AI²-Active Safety: AI-enabled Interaction-aware Active Safety Analysis with Vehicle Dynamics

Wu, K., Li, Z., Li, S., Ye, X., Lord, D., Zhou, Y.

Under Review · 2026

TR-C

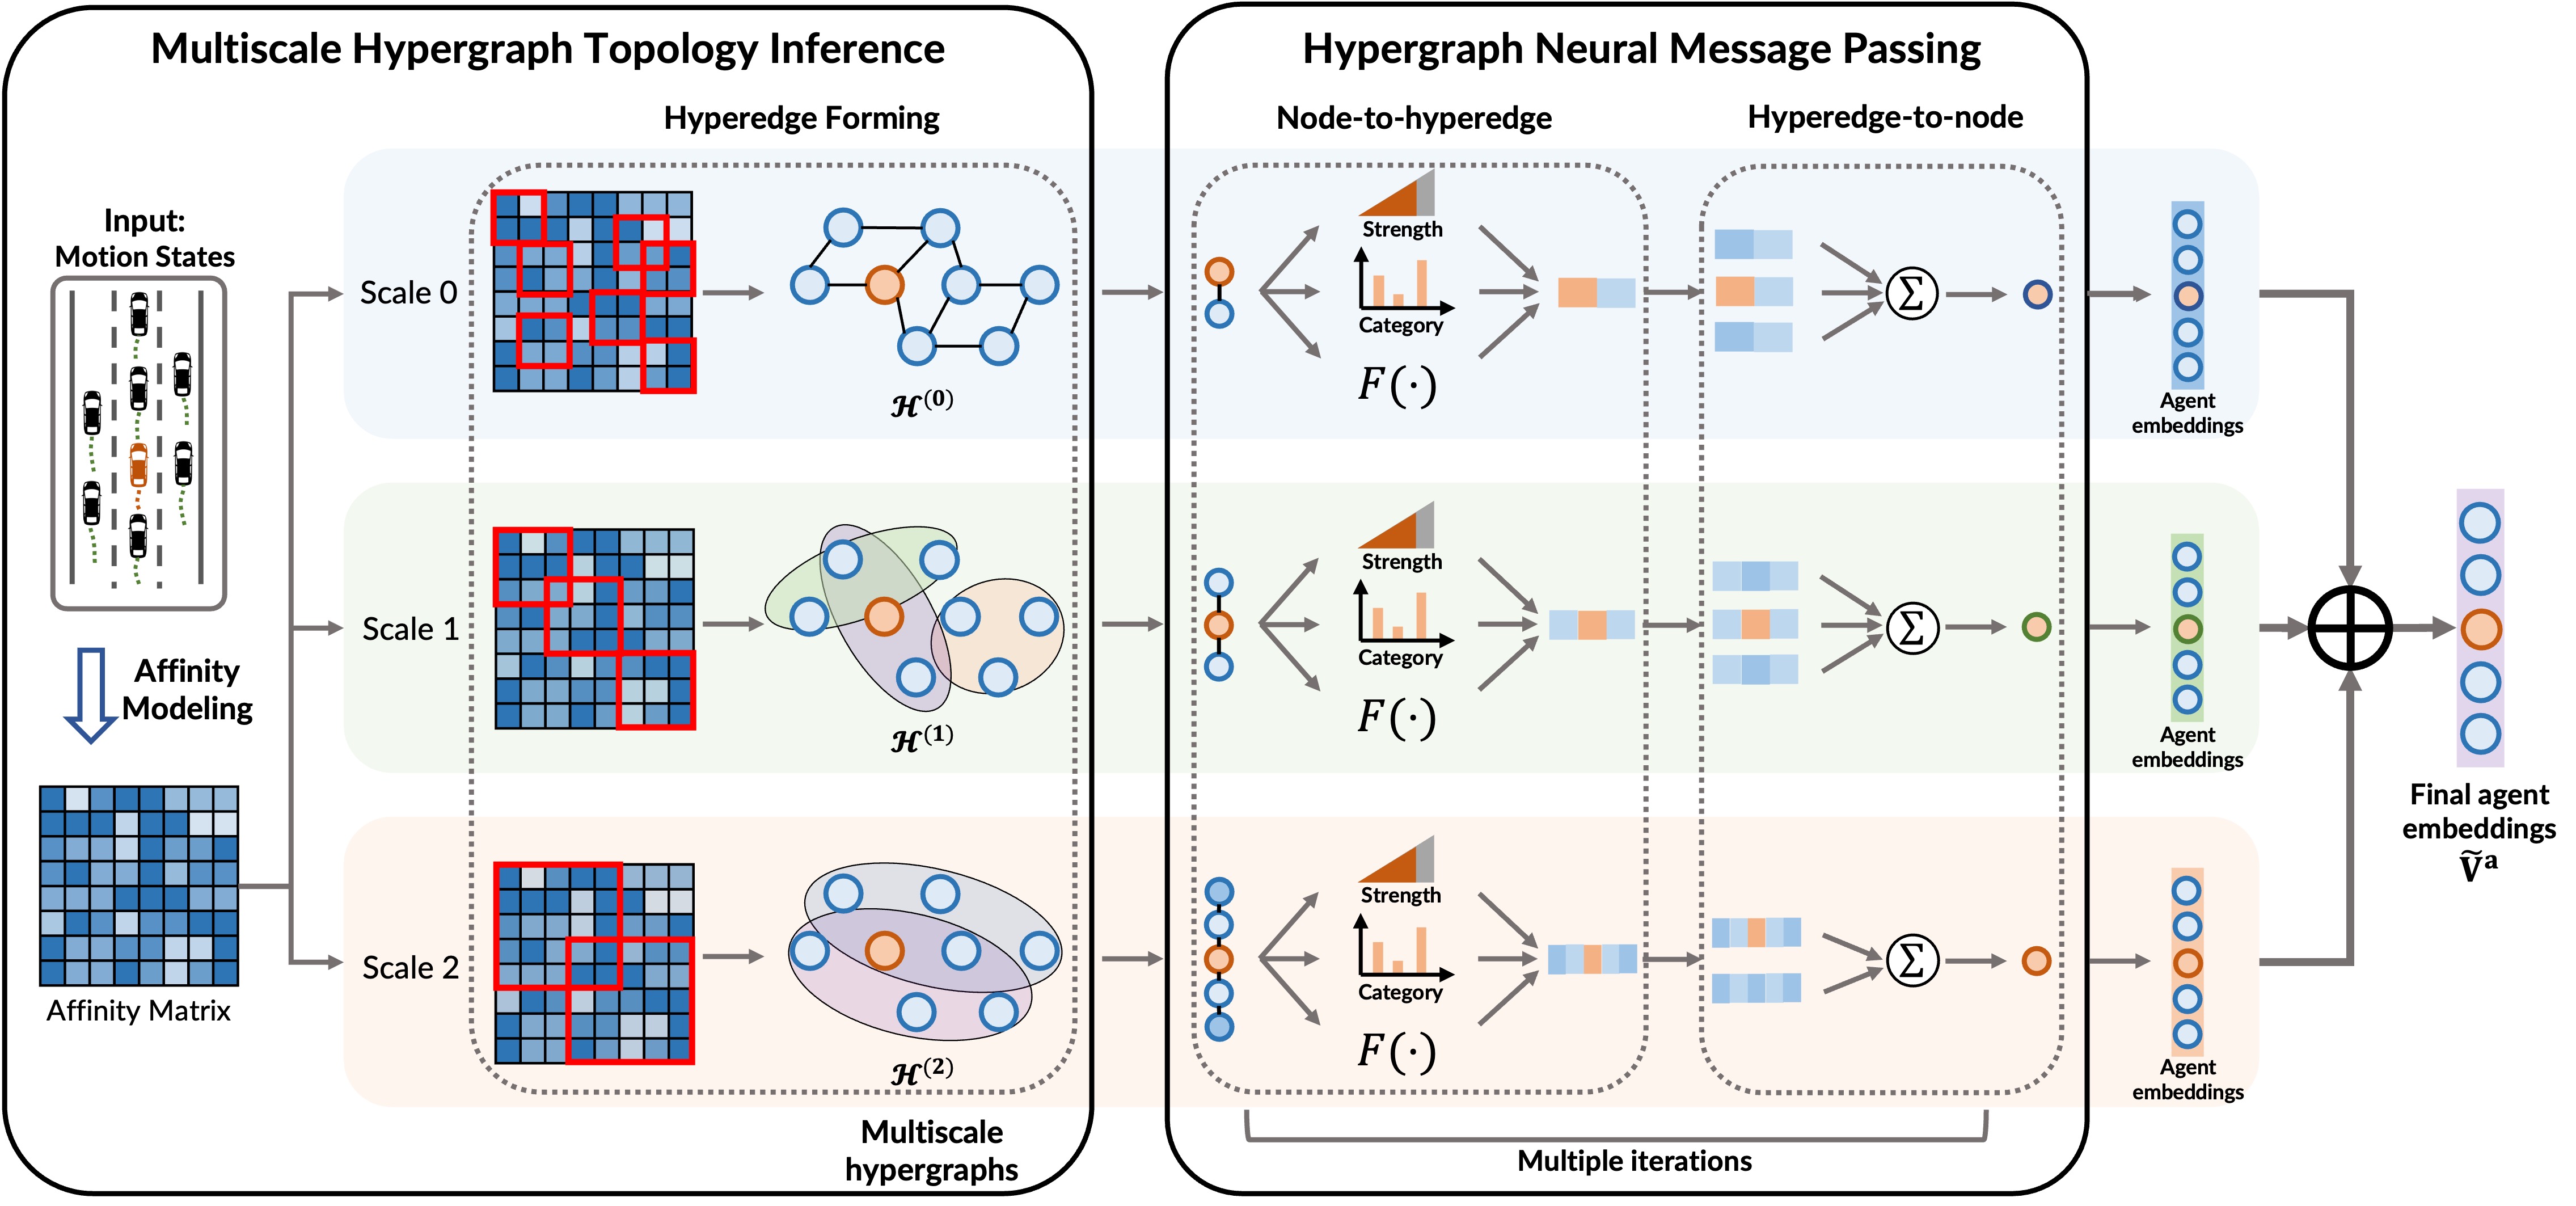
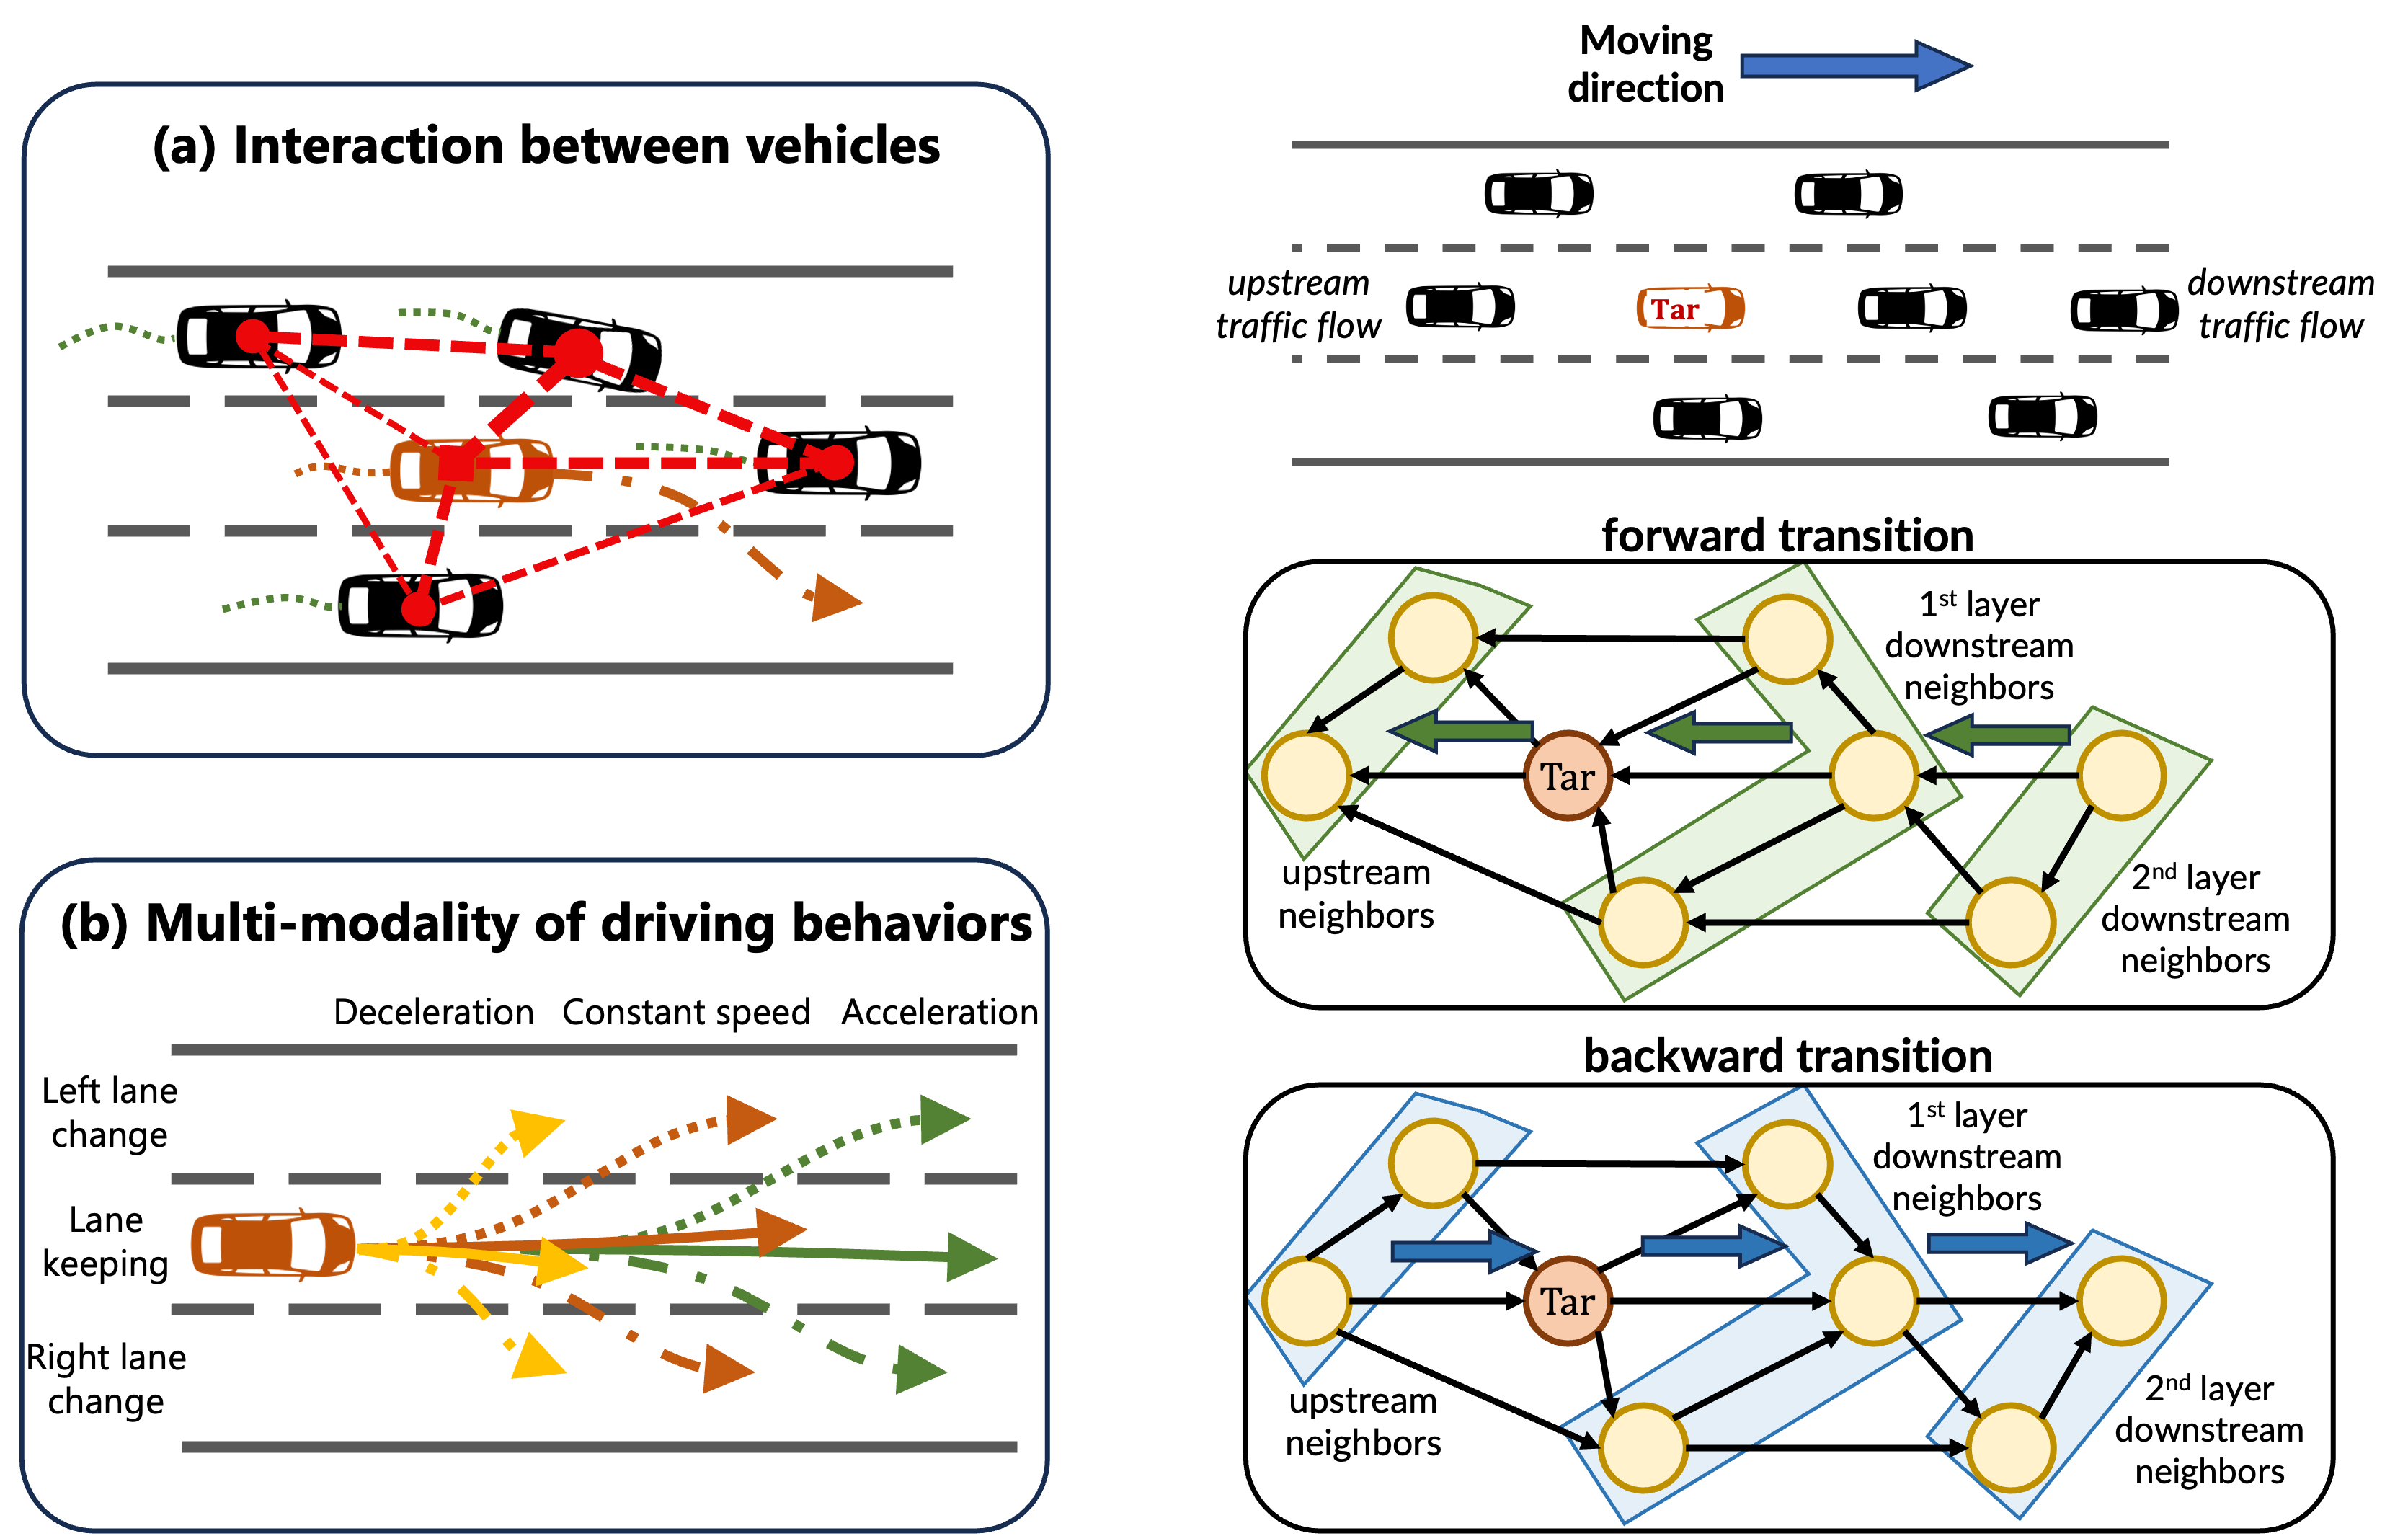
Hypergraph-based Motion Generation with Multi-modal Interaction Relational Reasoning

Wu, K., Zhou, Y., Shi, H., Lord, D., Ran, B., Ye, X.

Transportation Research Part C: Emerging Technologies · 2025
IEEE T-IV

Graph-Based Interaction-Aware Multimodal 2D Vehicle Trajectory Prediction Using Diffusion Graph Convolutional Networks

Wu, K., Zhou, Y., Shi, H., Li, X., Ran, B.

IEEE Transactions on Intelligent Vehicles · 2024
COMMTR

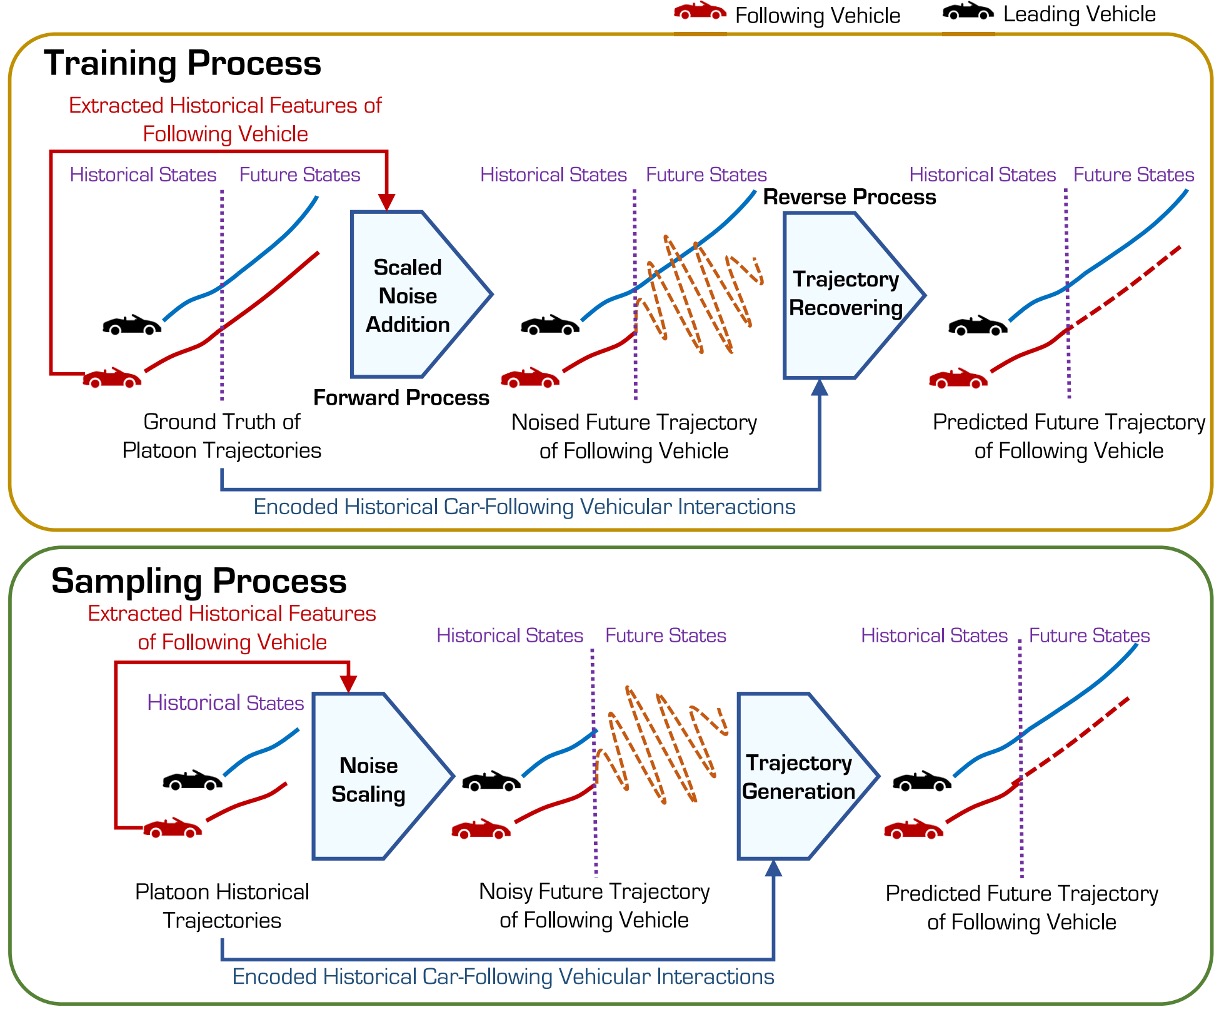
FollowGen: A Scaled Noise Conditional Diffusion Model for Car-Following Trajectory Prediction

You, J., Gan, R., Tang, W., Huang, Z., Liu, J., Jiang, Z., Shi, H., Wu, K., Long, K., Fu, S., Chen, S., Ran, B.

Communications in Transportation Research · 2025
IEEE IoT-J

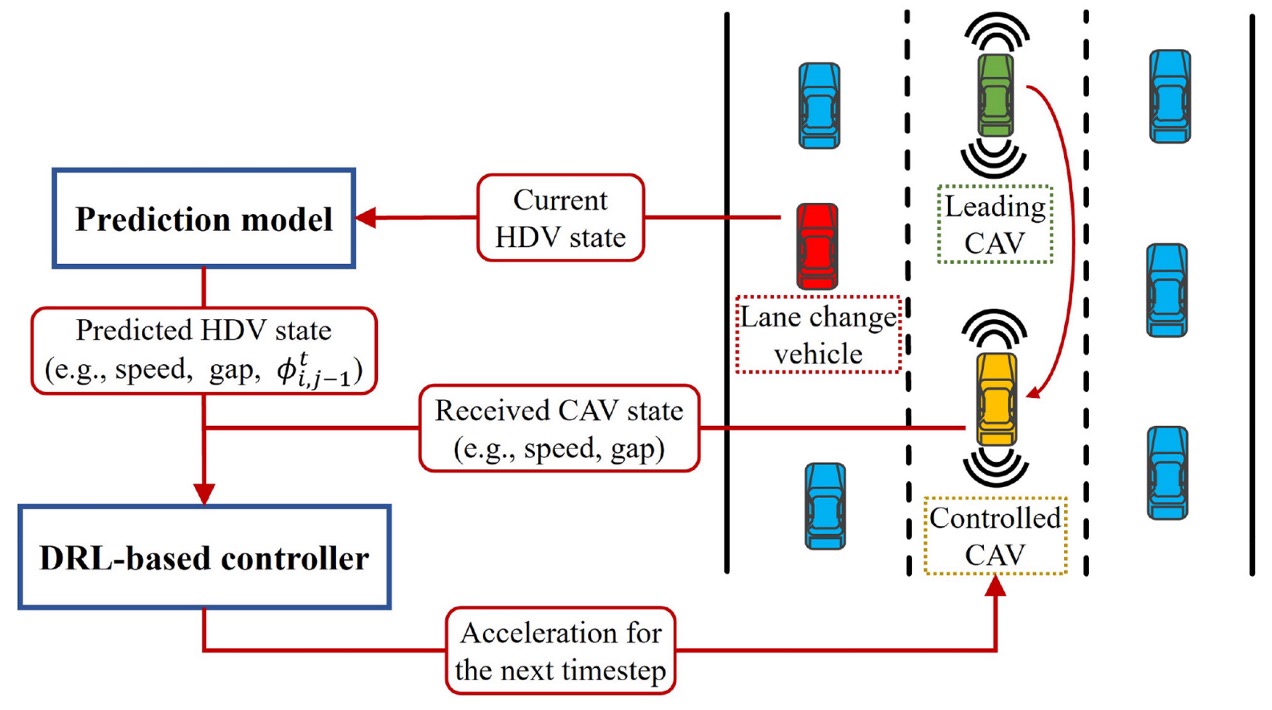
A Predictive Deep Reinforcement Learning Based Connected Automated Vehicle Anticipatory Longitudinal Control in a Mixed Traffic Lane Change Condition

Shi, H., Shi, K., Wu, K., Li, W., Zhou, Y., Ran, B.

IEEE Internet of Things Journal · 2025
TR-C

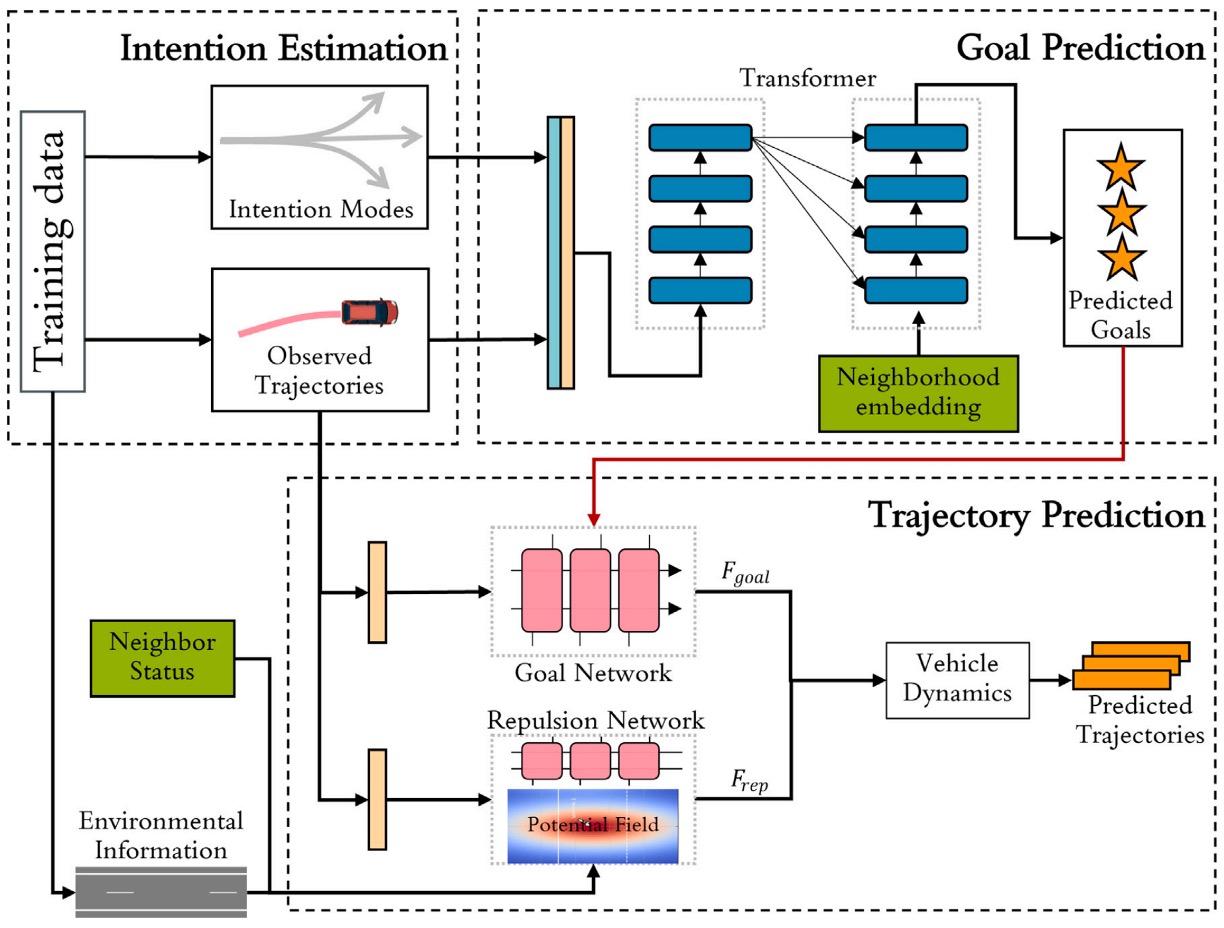
Goal-based neural physics vehicle trajectory prediction model

Gan, R., Shi, H., Li, P., Wu, K., An, B., Li, L., Ma, J., Ma, C., Ran, B.

Transportation Research Part C: Emerging Technologies · 2025
KBS

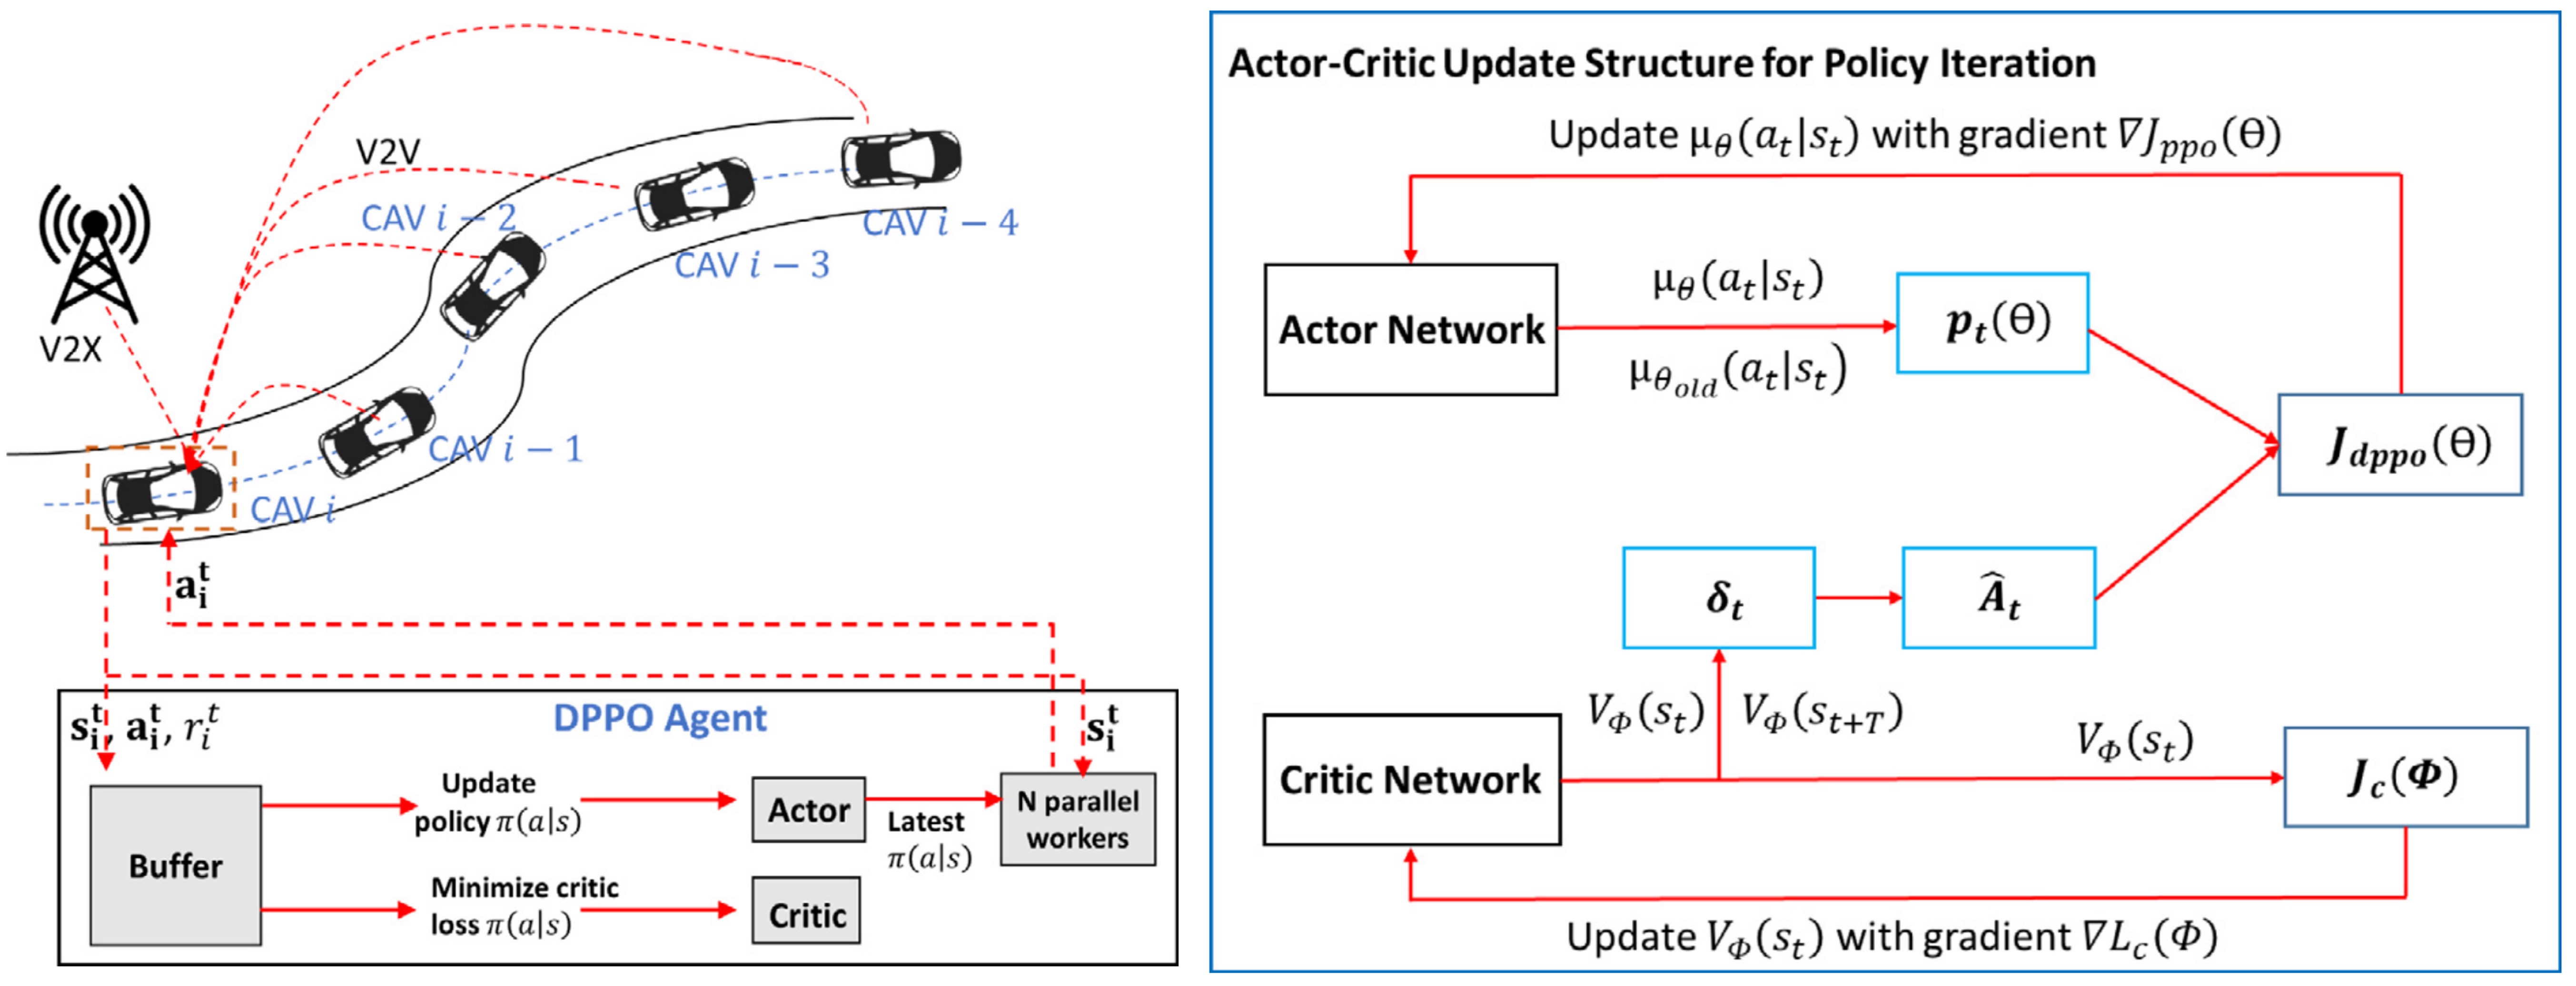
Physics-informed deep reinforcement learning-based integrated two-dimensional car-following control strategy for connected automated vehicles

Shi, H., Zhou, Y., Wu, K., Chen, S., Ran, B., Nie, Q.

Knowledge-Based Systems · 2023

TRR

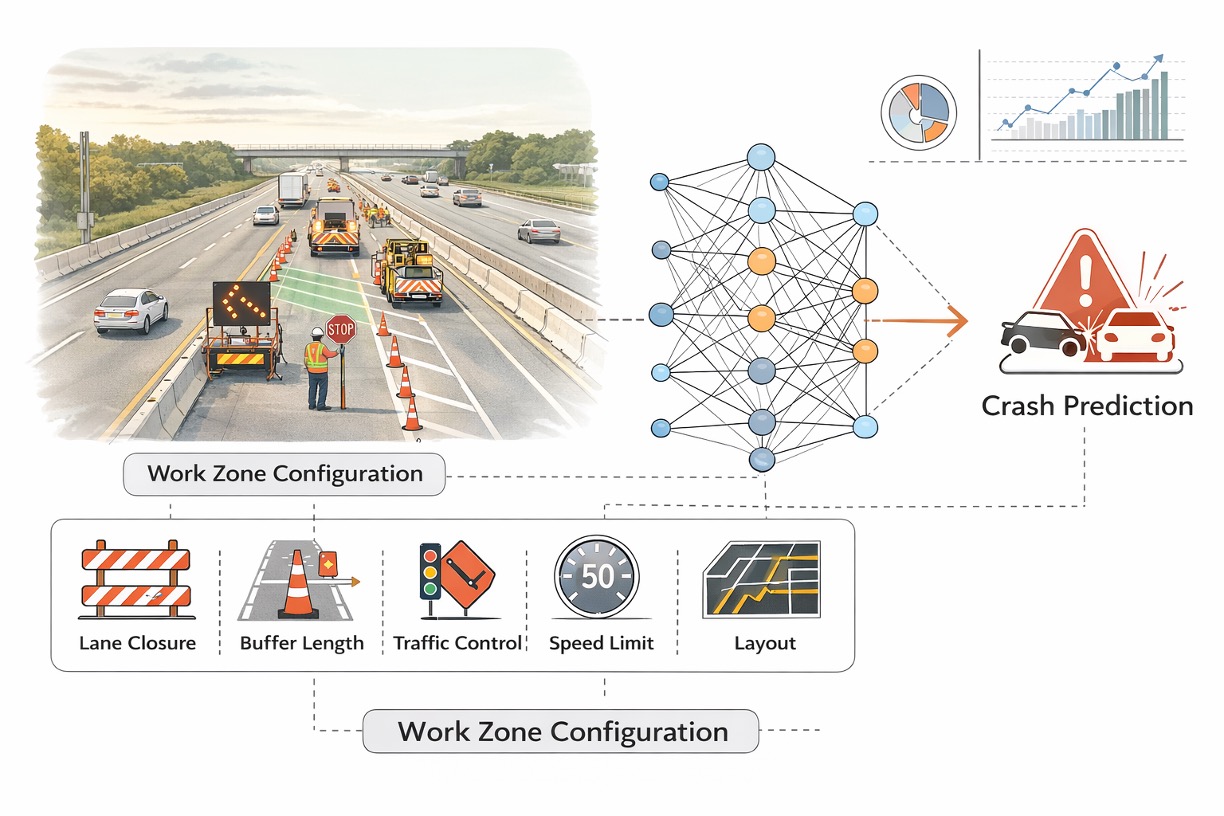
Work zone crash occurrence prediction based on planning stage work zone configurations using an artificial neural network

Cheng, Y., Wu, K., Li, H., Parker, S., Ran, B., Noyce, D.

Transportation research record · 2022

TR-C

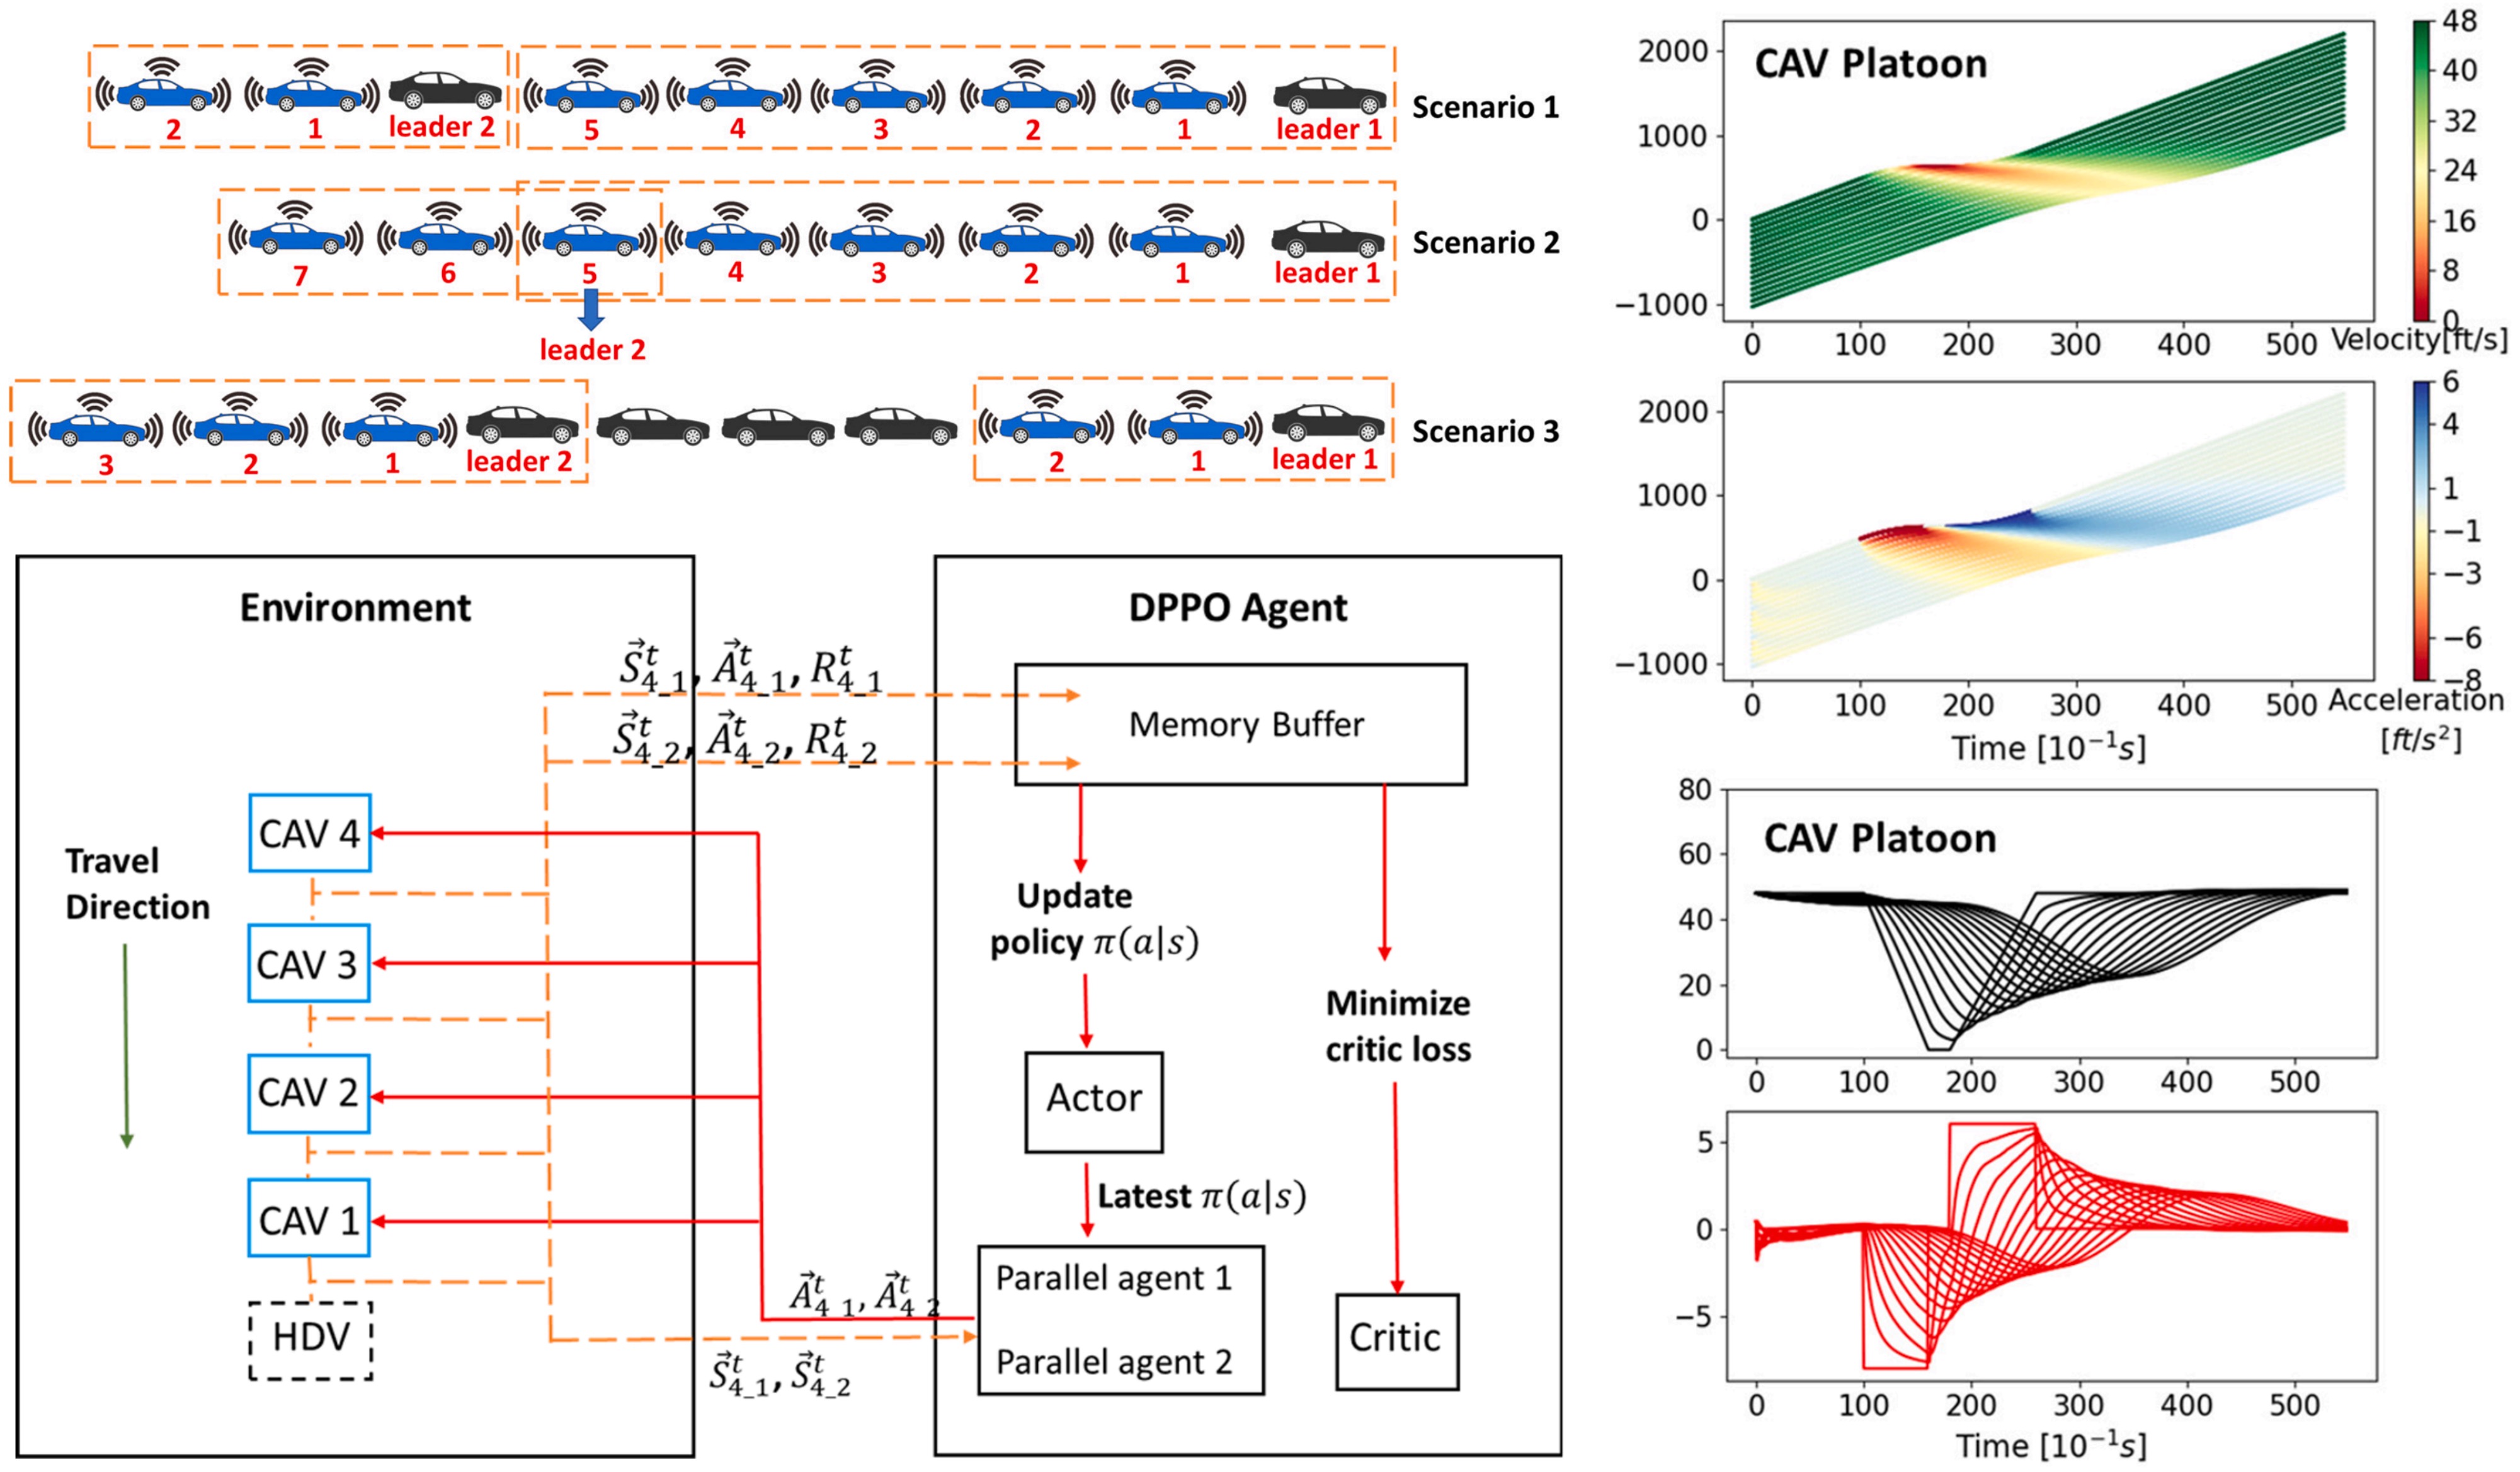
Connected automated vehicle cooperative control with a deep reinforcement learning approach in a mixed traffic environment

Shi, H., Zhou, Y., Wu, K., Wang, X., Lin, Y., Ran, B.

Transportation Research Part C: Emerging Technologies · 2021

Agentic Mobility & Foundation Models

Agentic systems and multi-agent orchestration; LLM/VLM-enabled reasoning and control; Retrieval-augmented intelligence; Generative and long-tail scenario synthesis.
Under Review

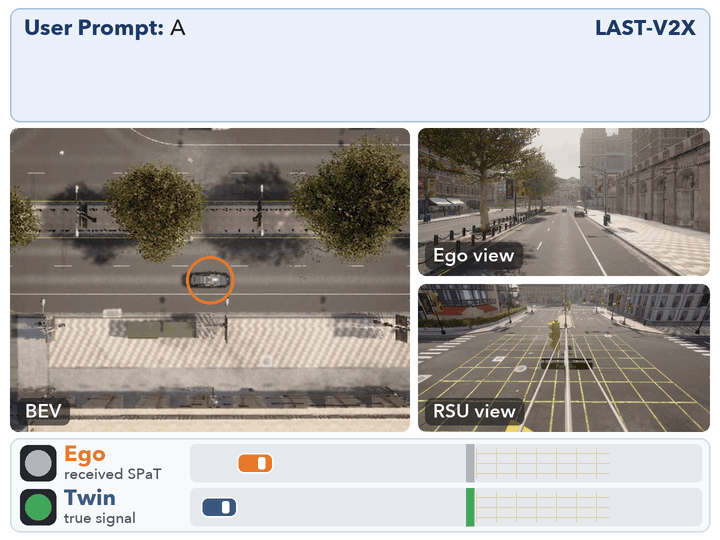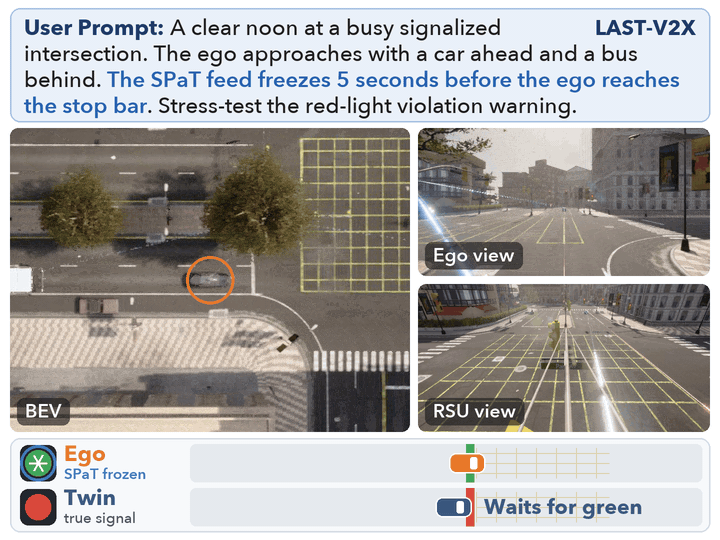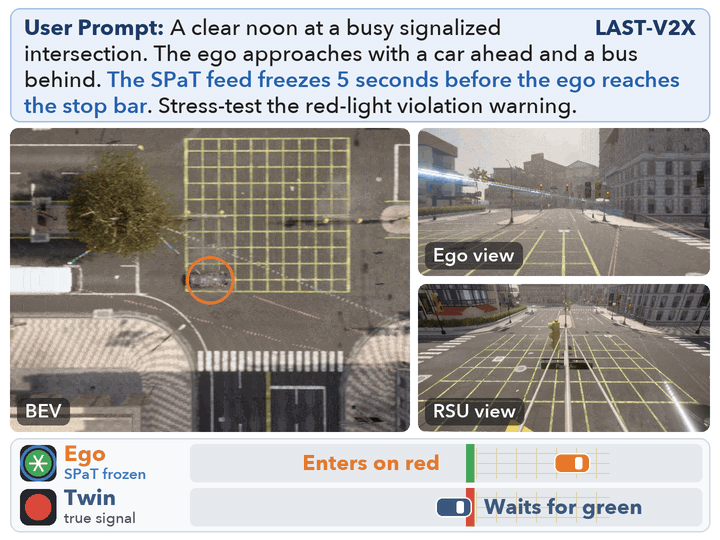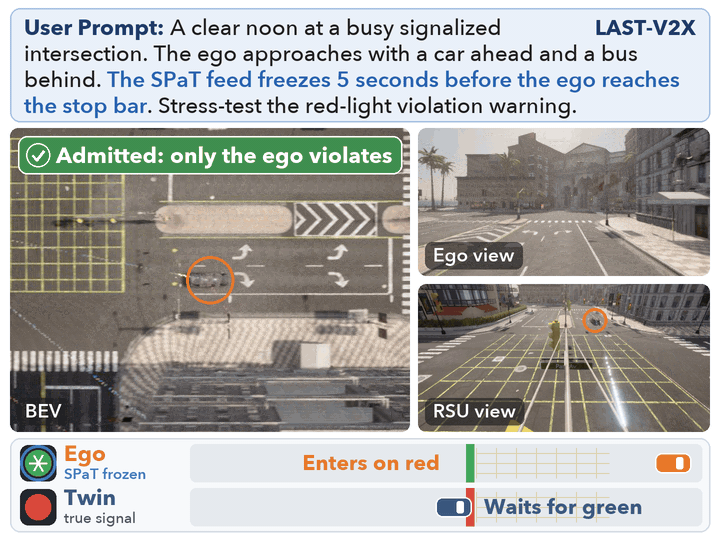
LAST-V2X: Language-Driven Adaptive Scenario Synthesis and Testing for Communication-Induced Failures in V2X Safety Applications

Wu, K., Zhang, H., Gan, R., Li, P., Jiang, J., Zhou, Y.

Under Review · 2026

Under Review

AURORA: A Natural Language–Driven Agentic Framework for Understanding, Reasoning, and Orchestrating Reliable Air–Ground Co-Simulation

Wu, K., Zhang, H., Gan, R., Gao, X., Li, X., Tu, Z., Zhou, Y.

Under Review · 2026

arXiv

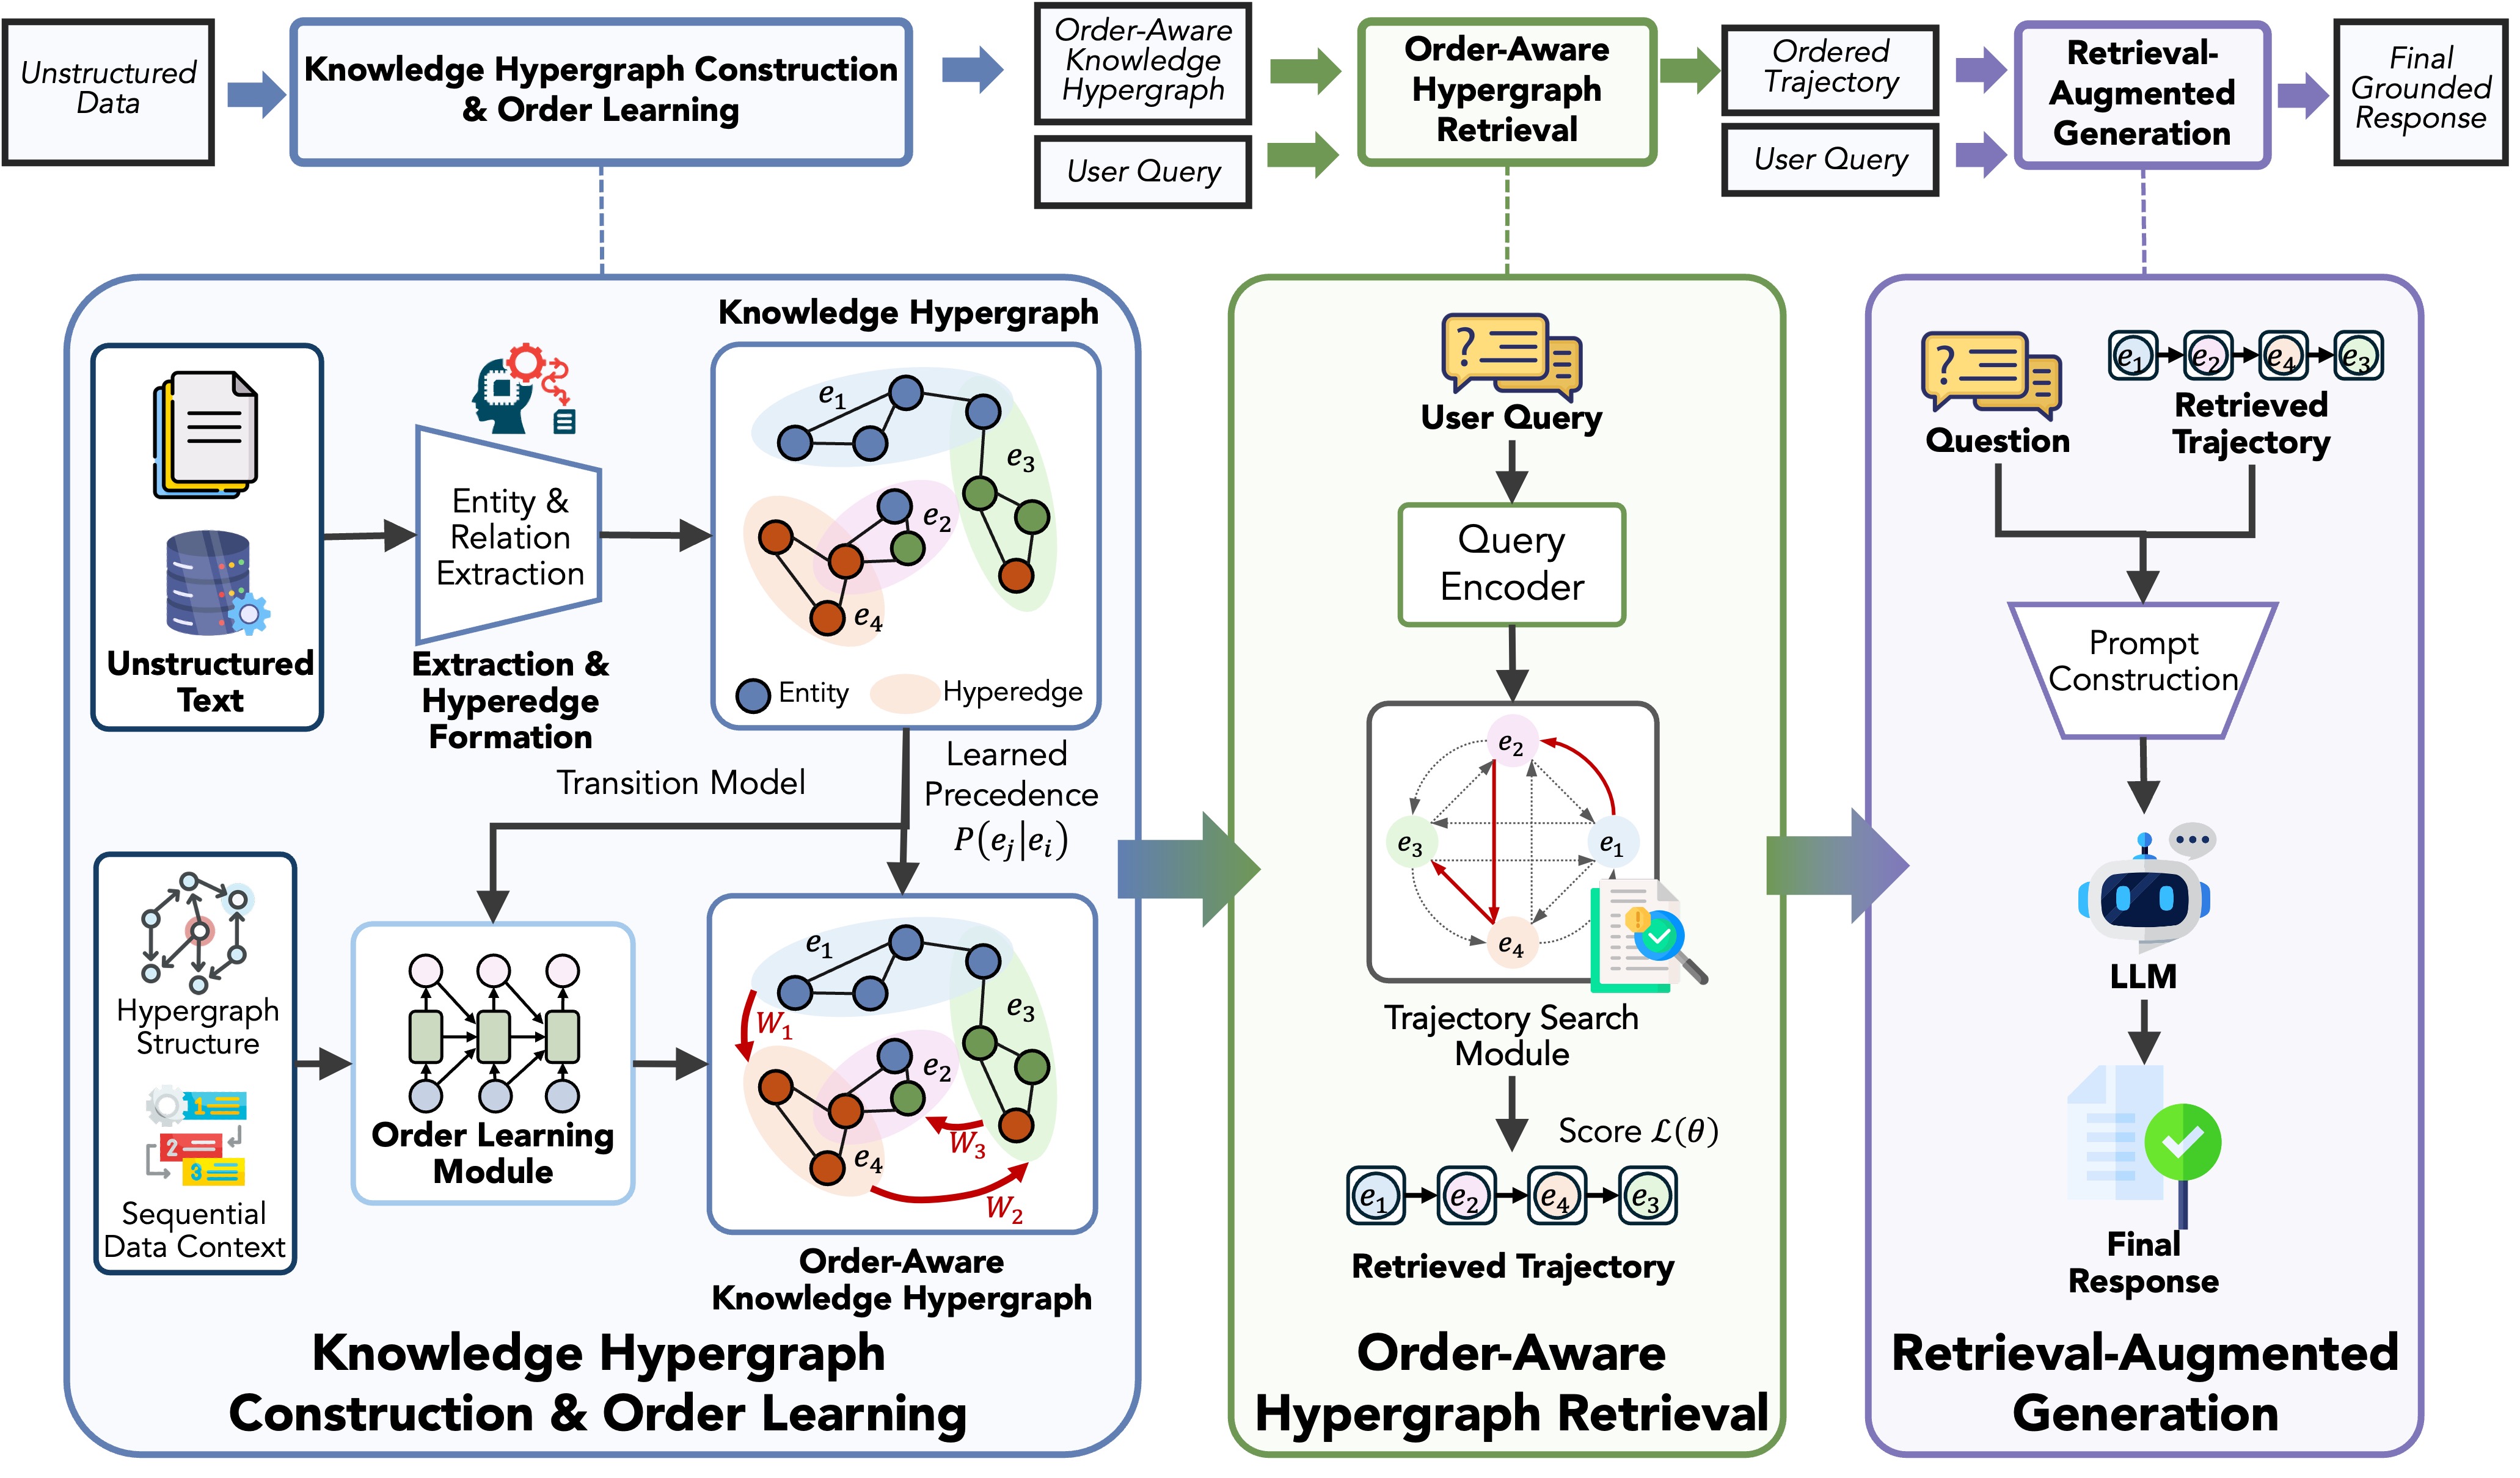
Knowledge Is Not Static: Order-Aware Hypergraph RAG for Language Models

Wu, K., Kuai, C., Li, Z., Jiang, J., Shen, S., Wang, S., Hu, C., Tu, Z., Zhou, Y.

Under Review · 2026

arXiv

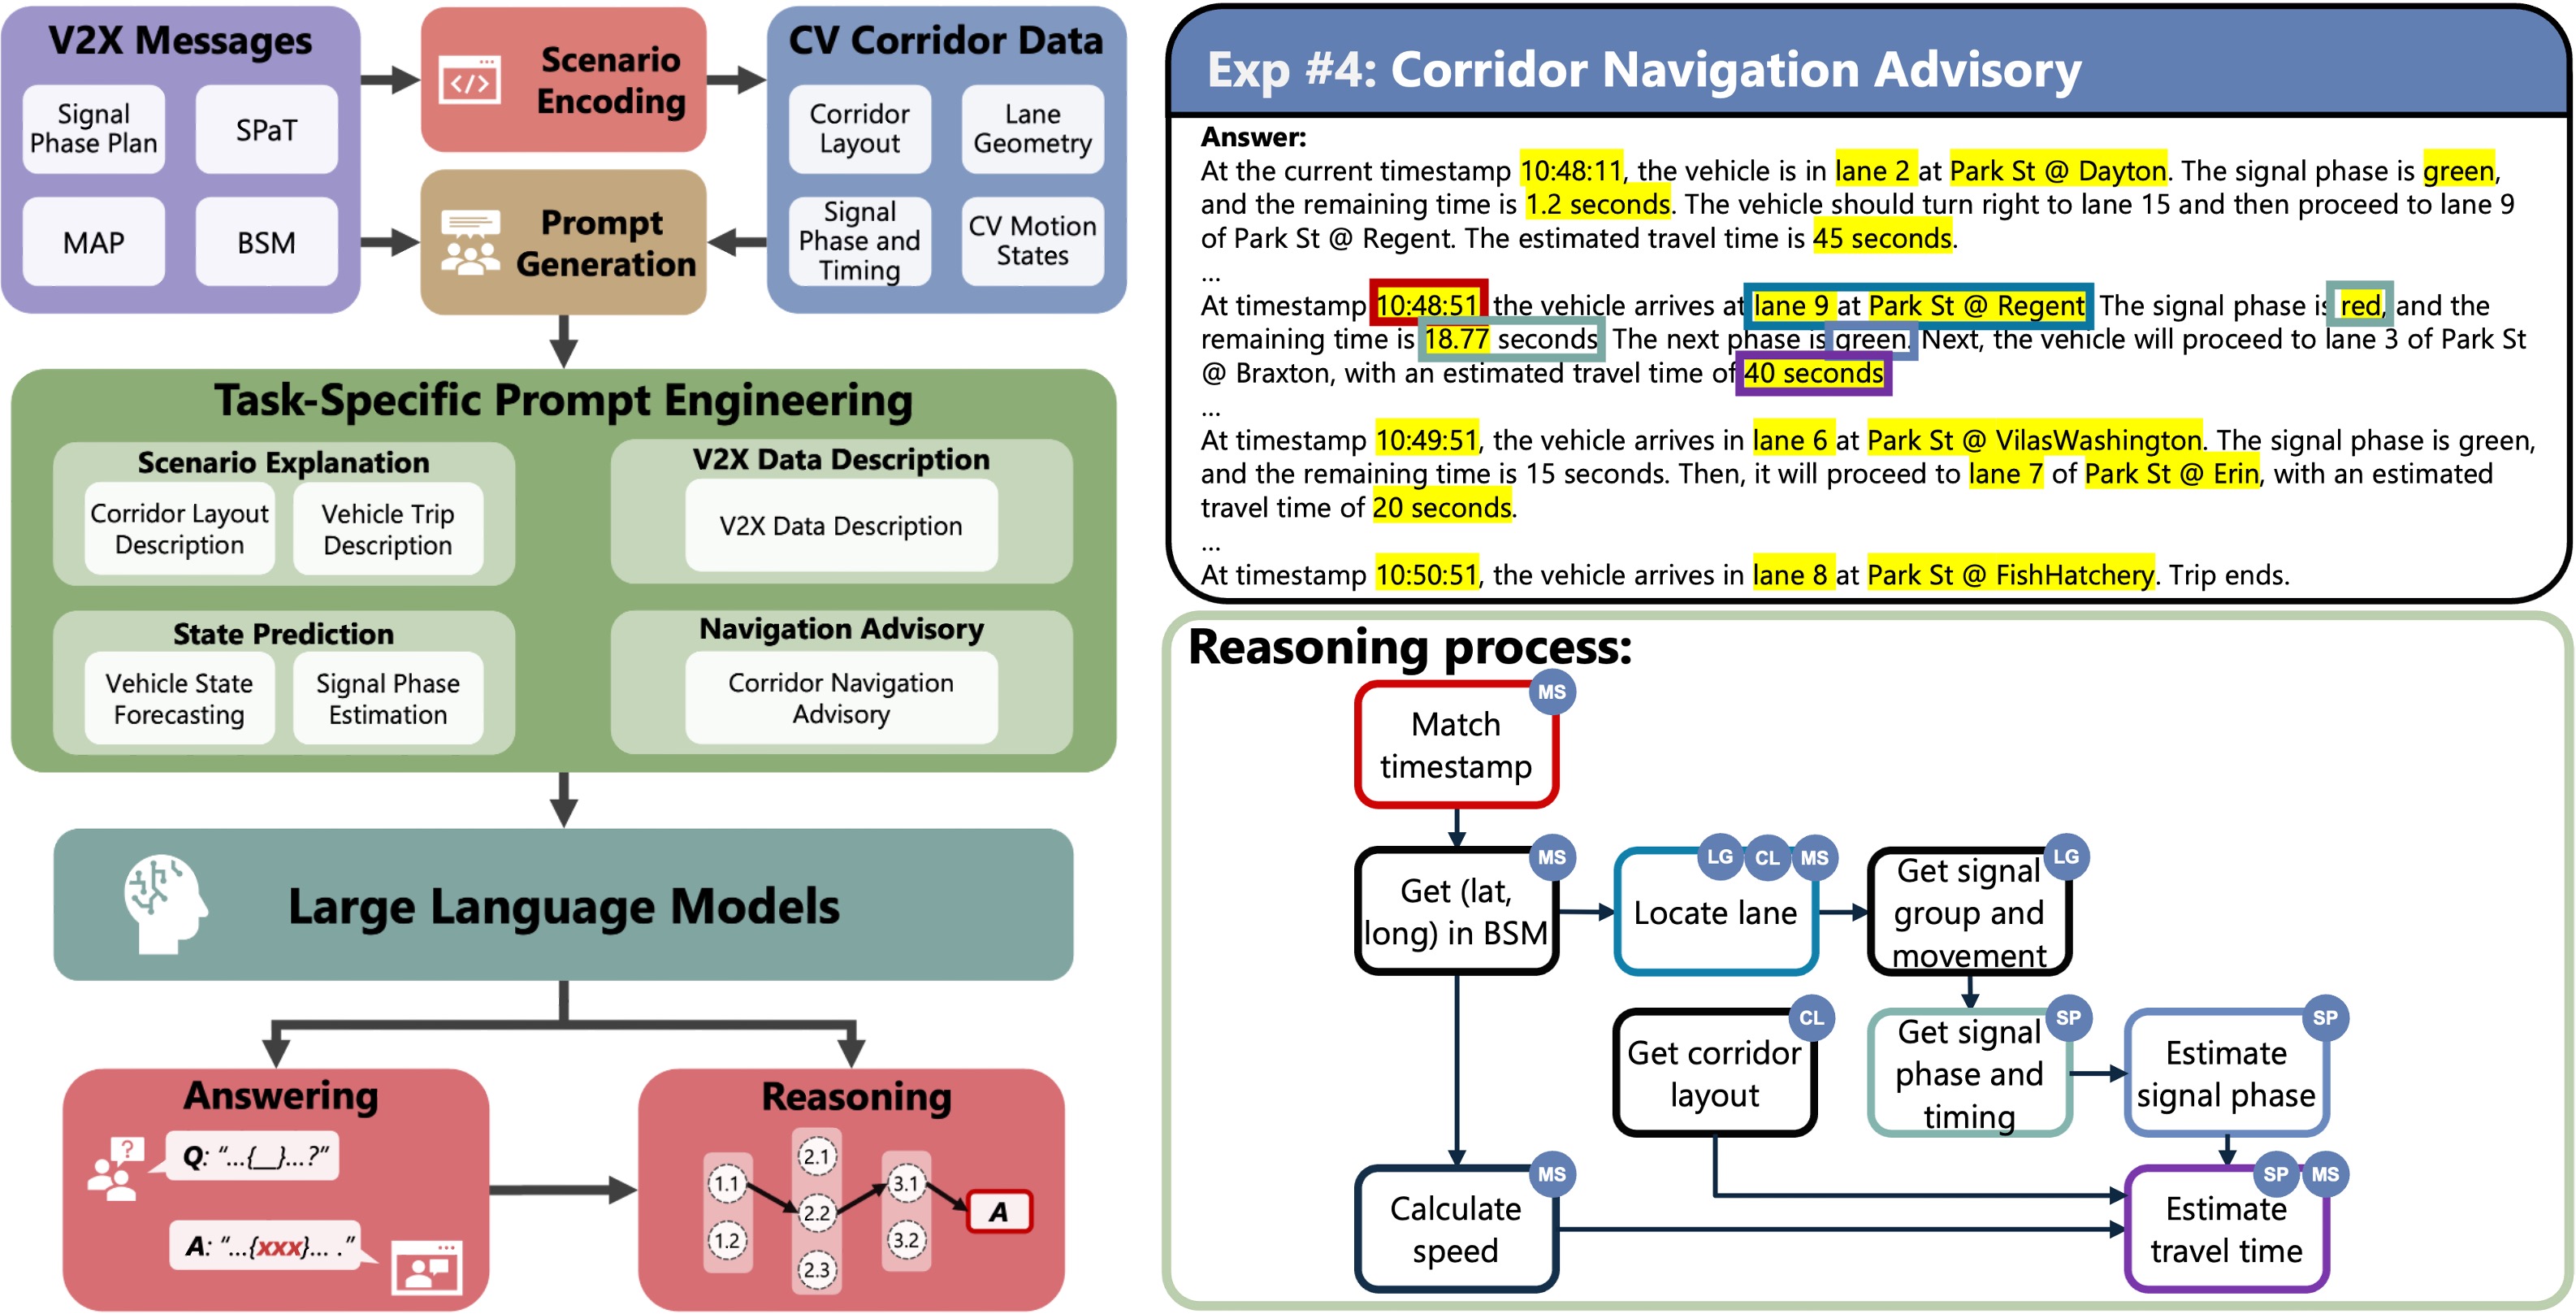
V2X-LLM: Enhancing V2X Integration and Understanding in Connected Vehicle Corridors

Wu, K., Li, P., Zhou, Y., Gan, R., You, J., Cheng, Y., Zhu, J., Parker, S. T., Noyce, D., Ran, B., Tu, Z.

Under Review · 2026

TR-C

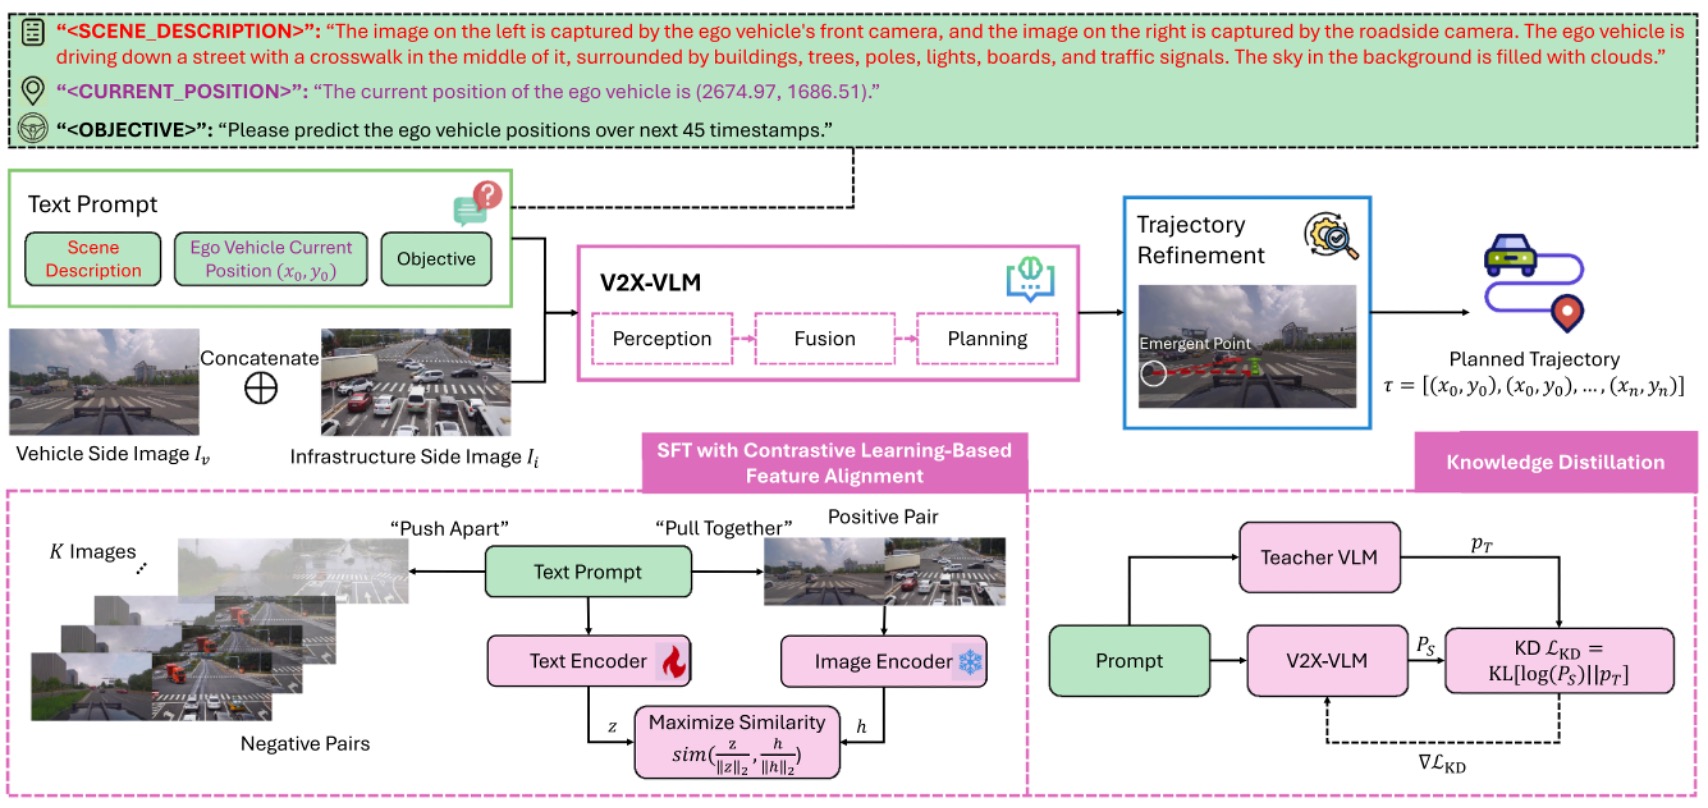
V2X-VLM: End-to-End V2X Cooperative Autonomous Driving Through Large Vision Language Models

You, J., Shi, H., Jiang, Z., Huang, Z., Gan, R., Wu, K., Cheng, X., Li, X., Ran, B.

Transportation Research Part C: Emerging Technologies · 2026

Spatiotemporal & Geospatial AI

Graph/hypergraph learning; Higher-order networks; Spatiotemporal reconstruction and forecasting; Geospatial foundation models; Multimodal sensing and data fusion.
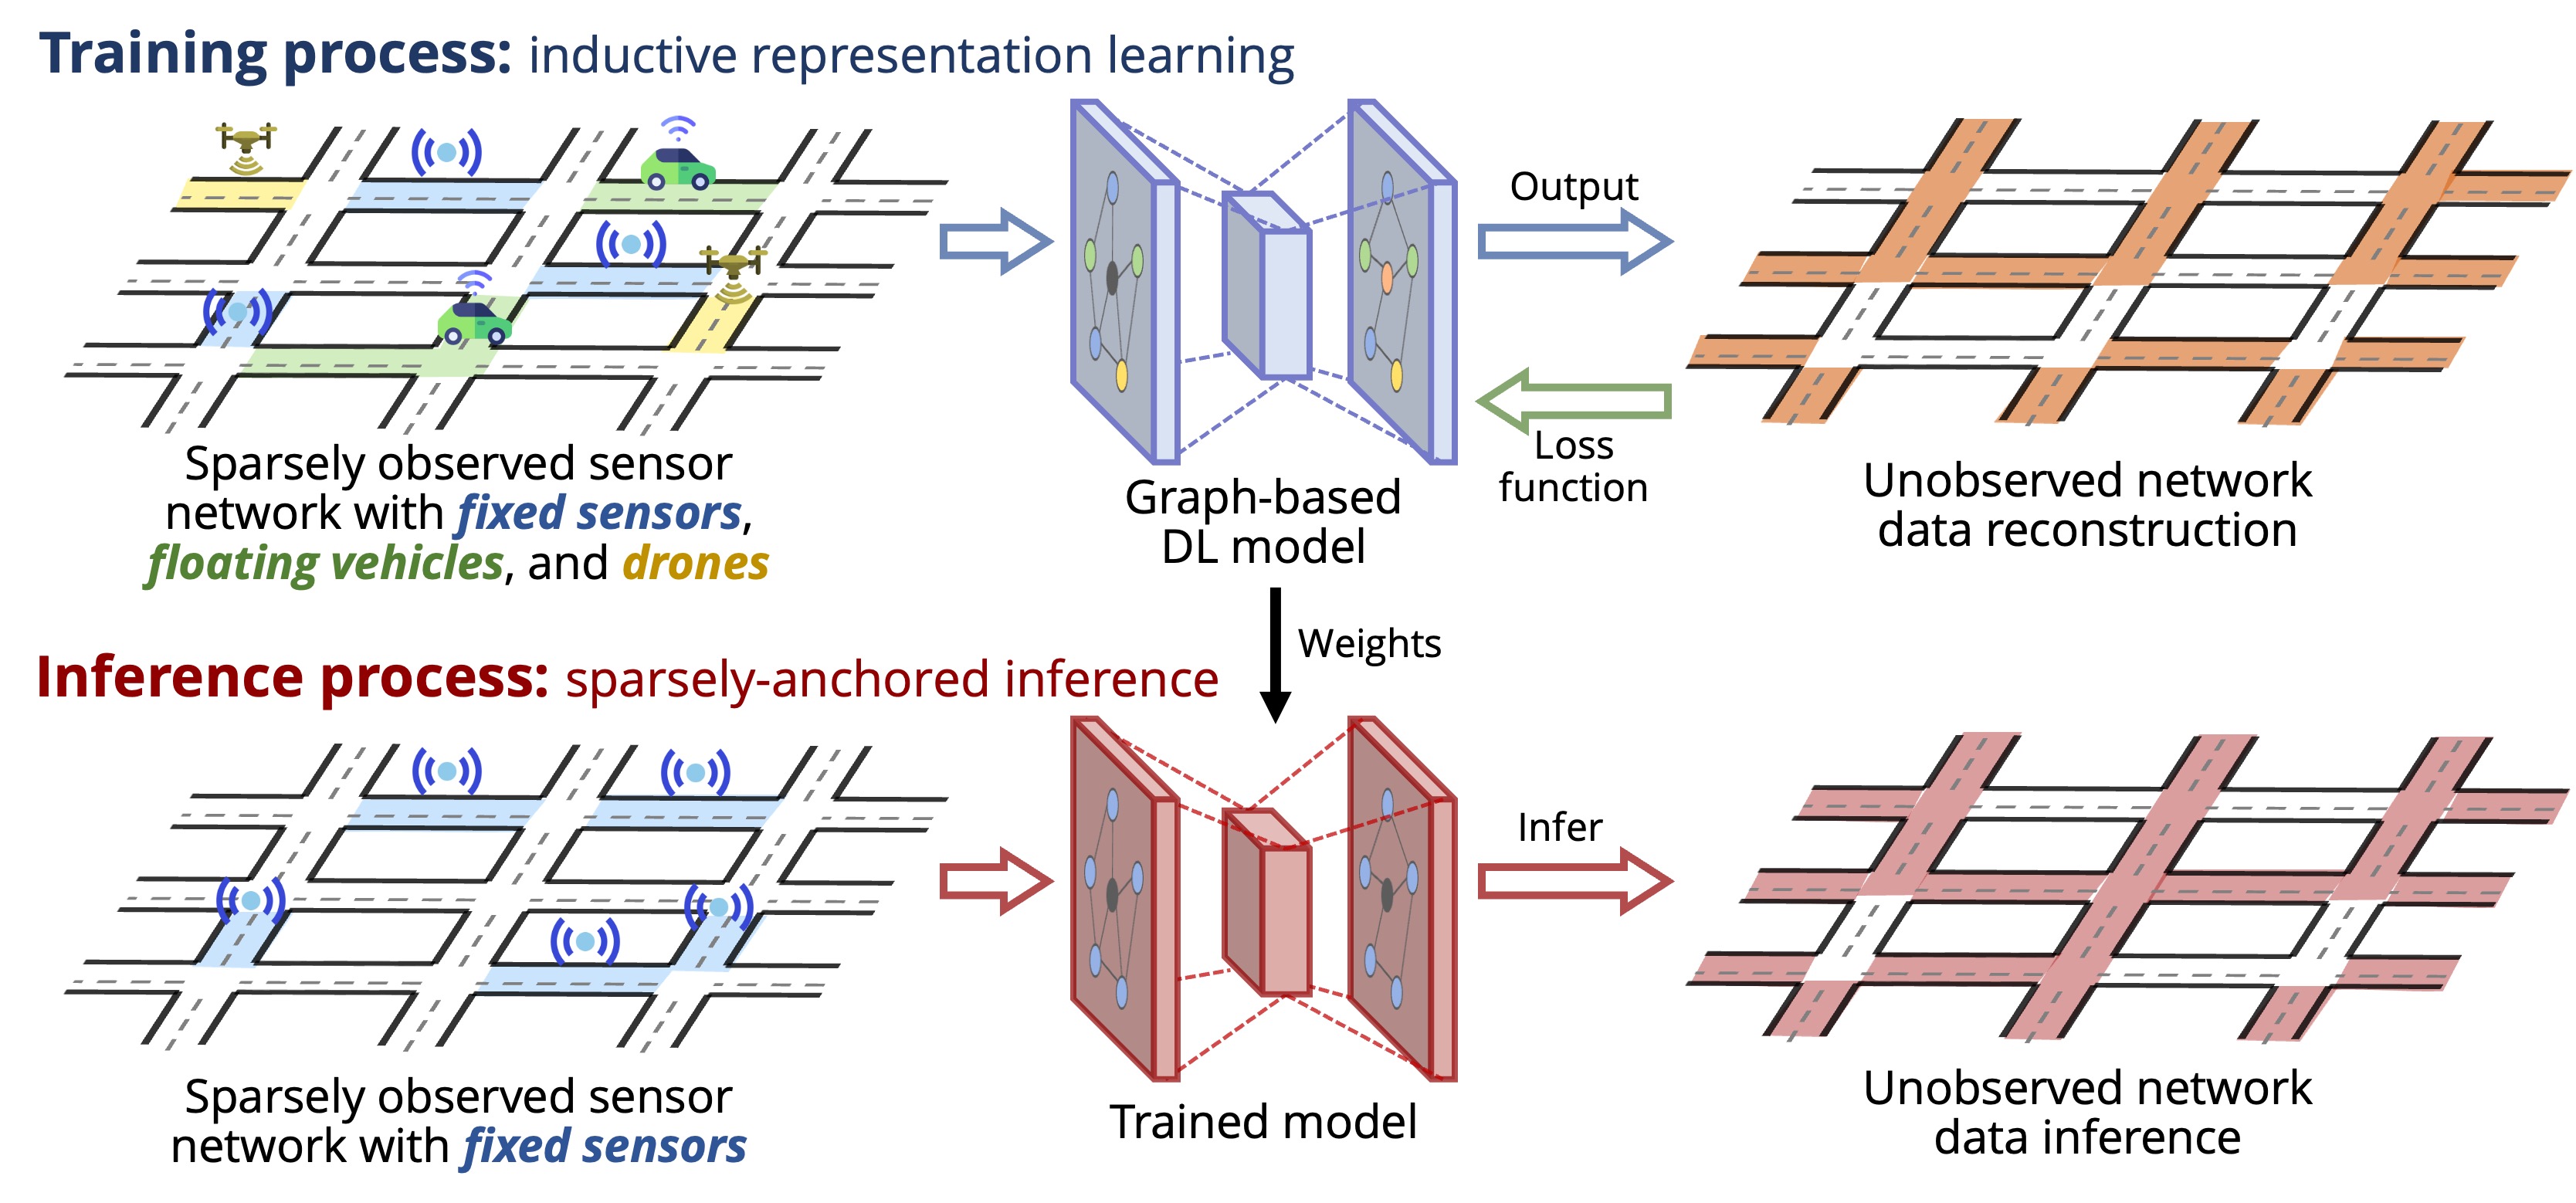
Nat. Commun.

A Deep Learning Enabled Economical Informatization Framework with Sparsely Located Sensors

Wu, K., Zhou, Y., Li, X., Ye, X., Tu, Z.

Nature Communications · 2026 (accepted in principle)
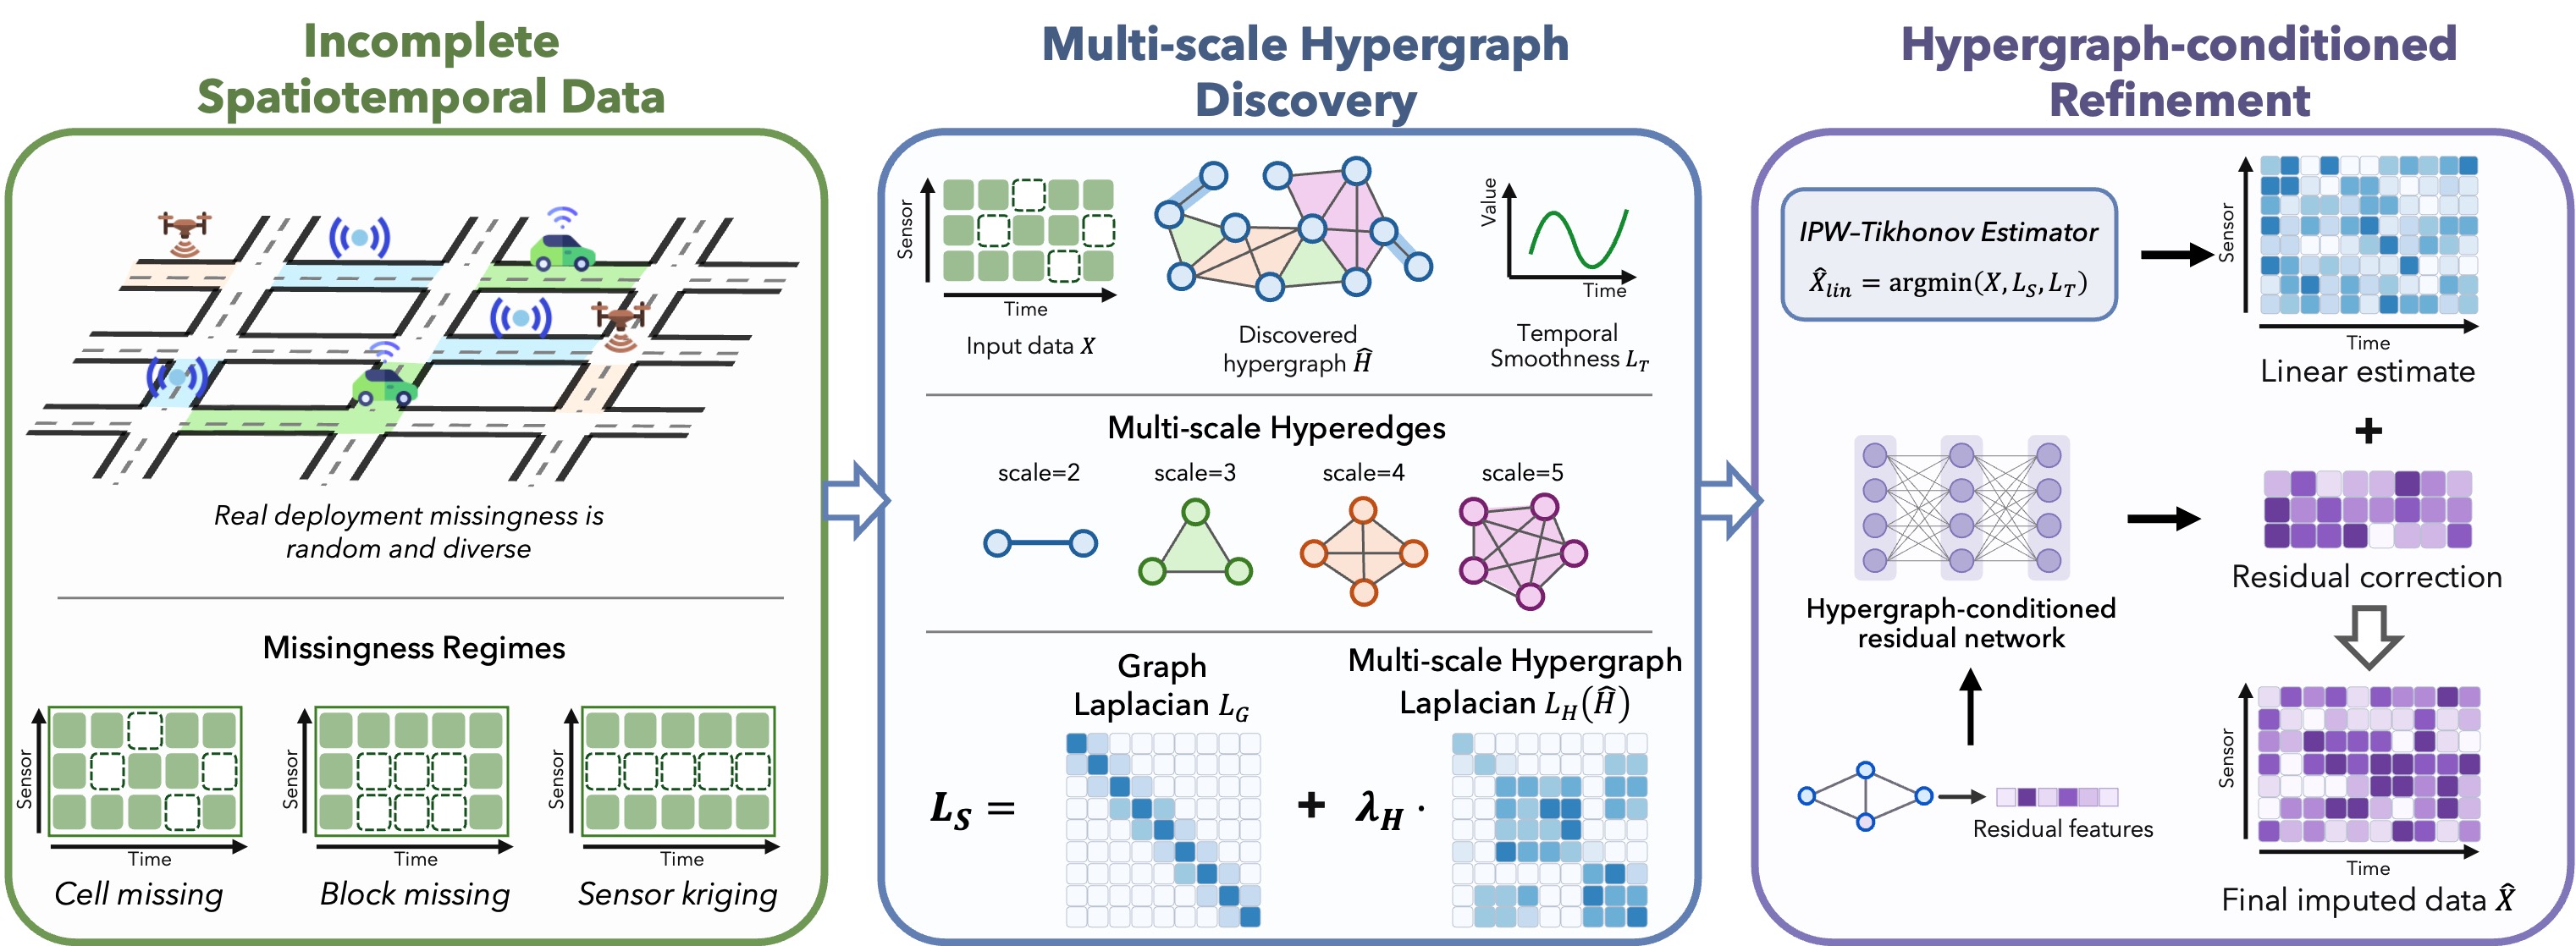
arXiv

Learning Higher-Order Structure from Incomplete Spatiotemporal Data: Multi-Scale Hypergraph Laplacians with Neural Refinement

Wu, K., Li, S., Li, Z., Fan, Z., Li, X., Zhou, Y.

Under Review · 2026

Digital Twins, World Models & Cyber-Physical Systems

Data-grounded and multi-fidelity digital twins; Generative world modeling; Physical–virtual closed-loop simulation; Resilience and safety-critical stress testing.
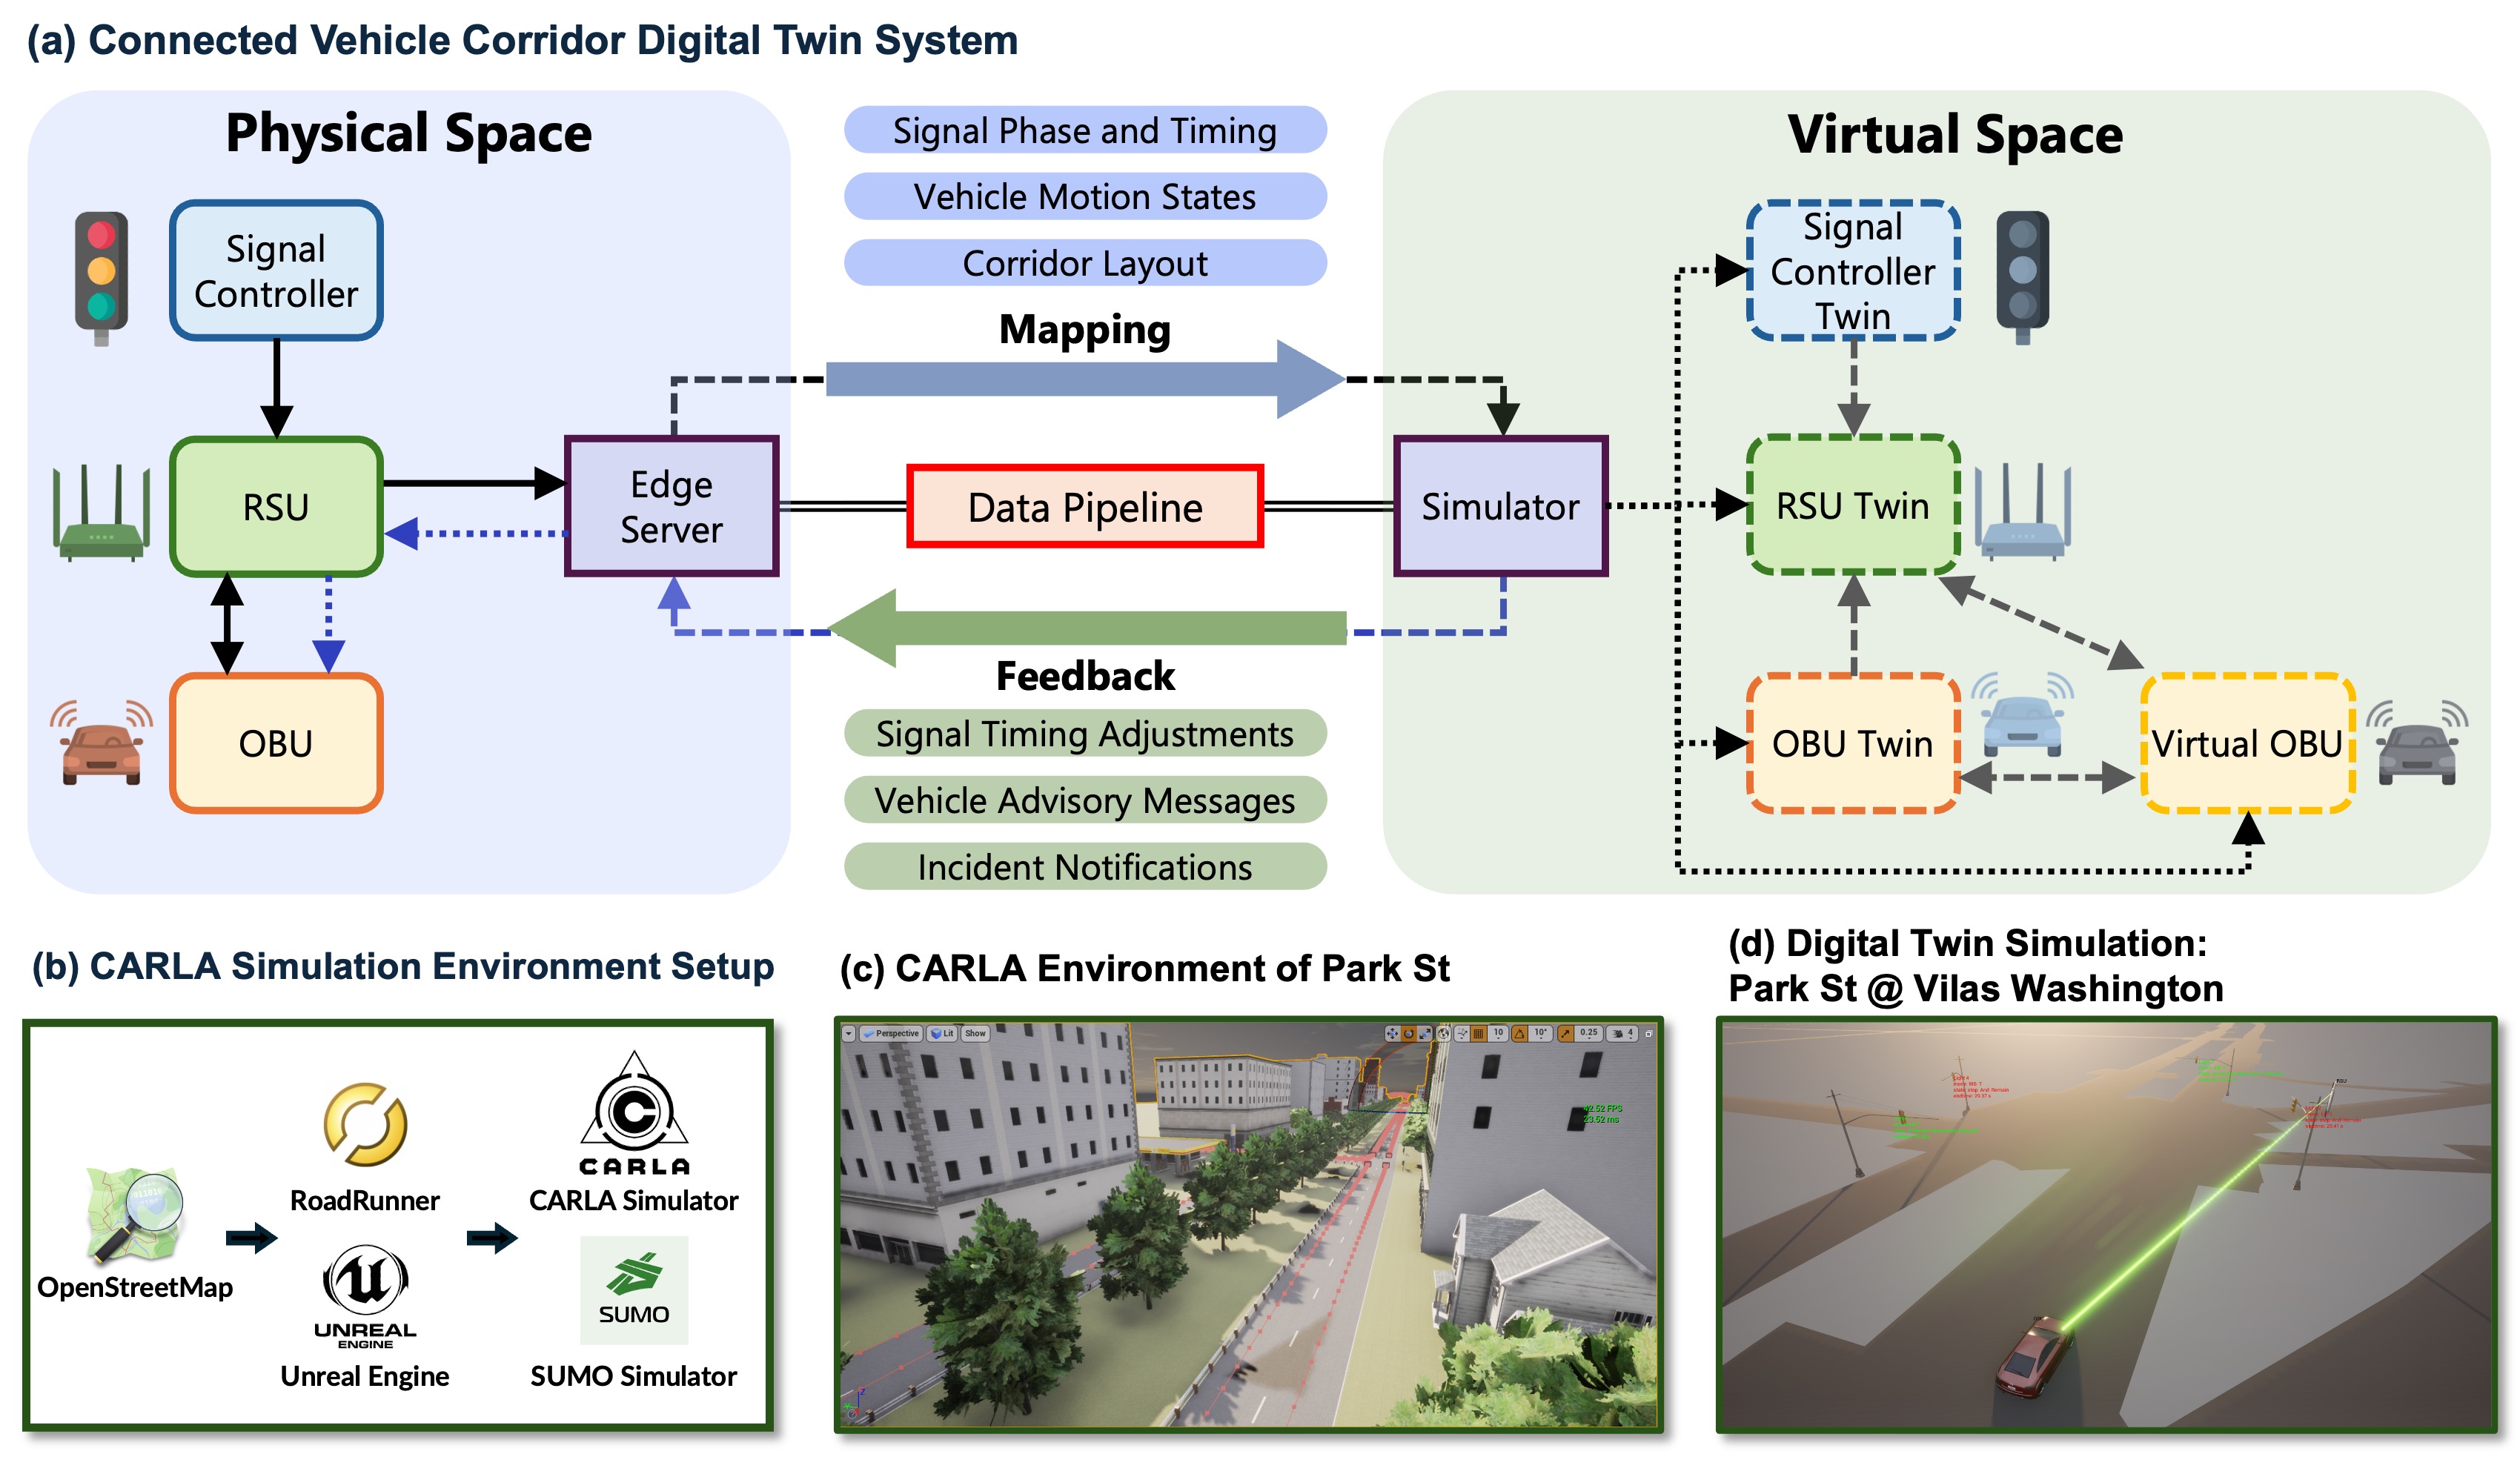
IEEE T-ITS

A Digital Twin Framework for Physical-Virtual Integration in Enhancing Connected Vehicle Corridor Data Pipeline

Wu, K., Li, P., Cheng, Y., Parker, S. T., Noyce, D., Ran, B., Ye, X.

IEEE Transactions on Intelligent Transportation Systems · 2025
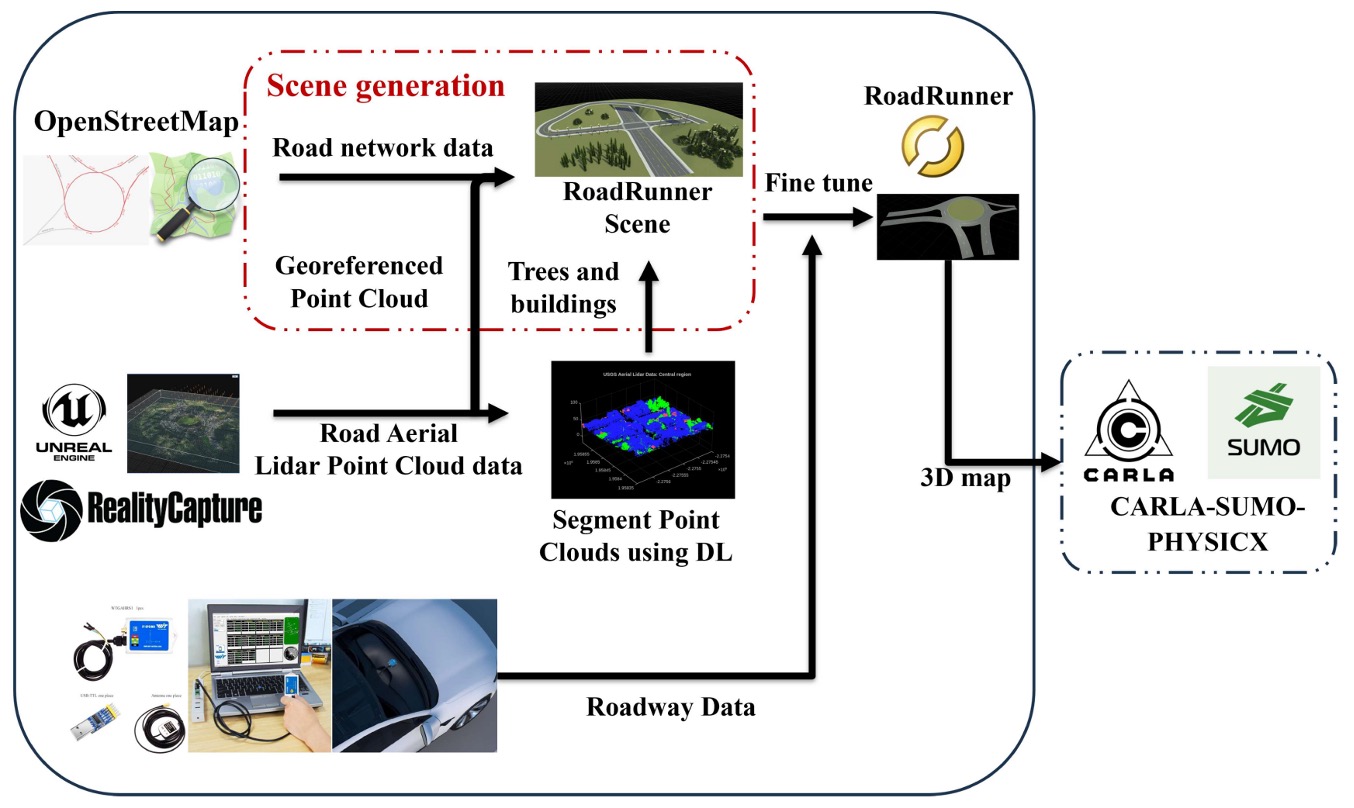
IEEE IoT-J

Virtual Roads, Smarter Safety: A Digital Twin Framework for Mixed Autonomous Traffic Analysis

Zhang, H., Yue, X., Tian, K., Li, S., Wu, K., Li, Z., Lord, D., Zhou, Y.

IEEE Internet of Things Journal · 2025

Connected & Cooperative Mobility Systems

V2X and air–ground cooperation; Vehicle–road–edge–cloud intelligence; Connected infrastructure analytics; Distributed sensing, communication, and control.
ASCE ICTD

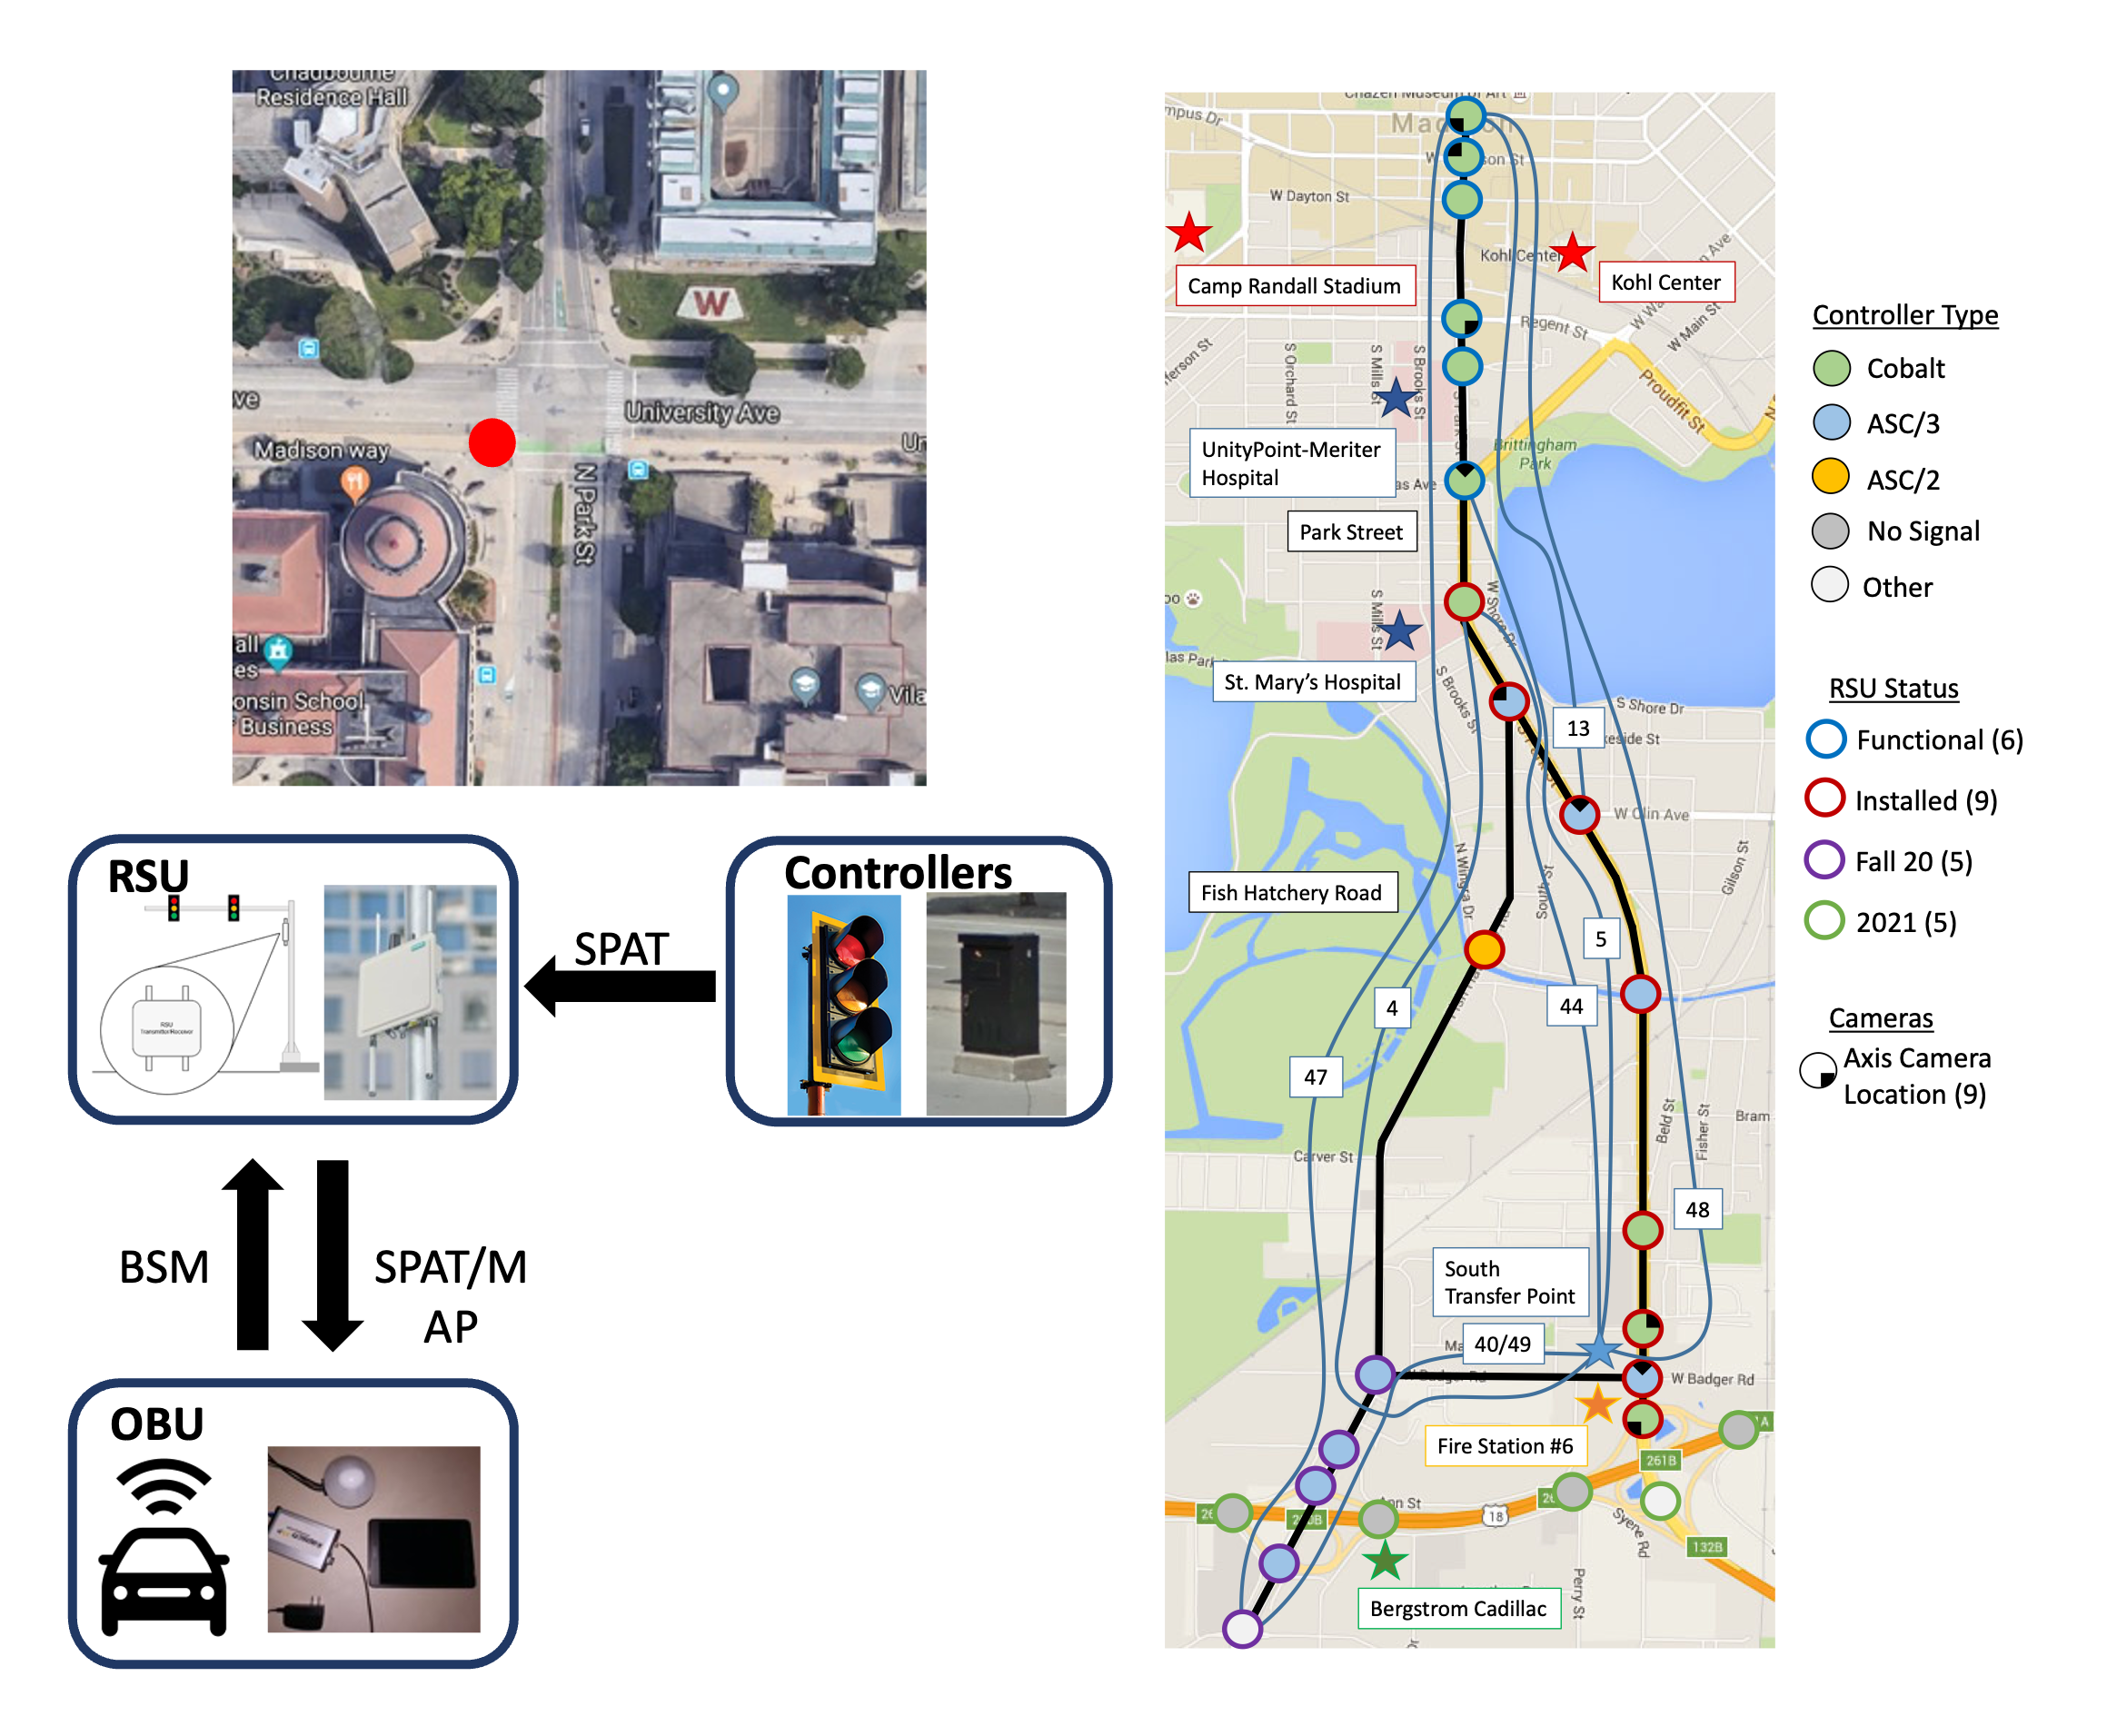
Development of the Data Pipeline for a Connected Vehicle Corridor

Wu, K., Cheng, Y., Parker, S. T., Ran, B., Noyce, D. A.

ASCE International Conference on Transportation and Development 2023 · 2023
arXiv
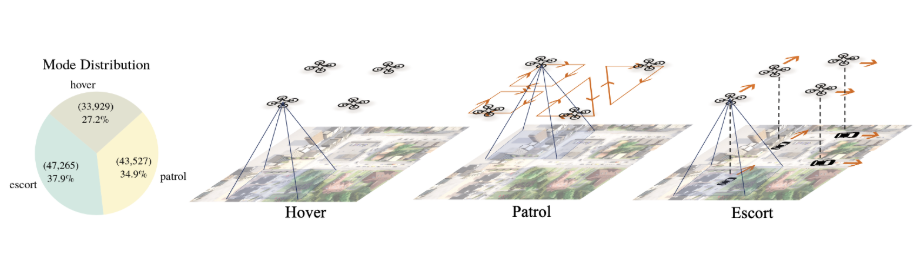
AirV2X: Unified Air-Ground Vehicle-to-Everything Collaboration

Gao, X., Wu, Y., Yang, F., Luo, X., Wu, K., Chen, X., Wang, Y., Liu, C., Zhou, Y., Tu, Z.

Under Review · 2025

IEEE T-IV

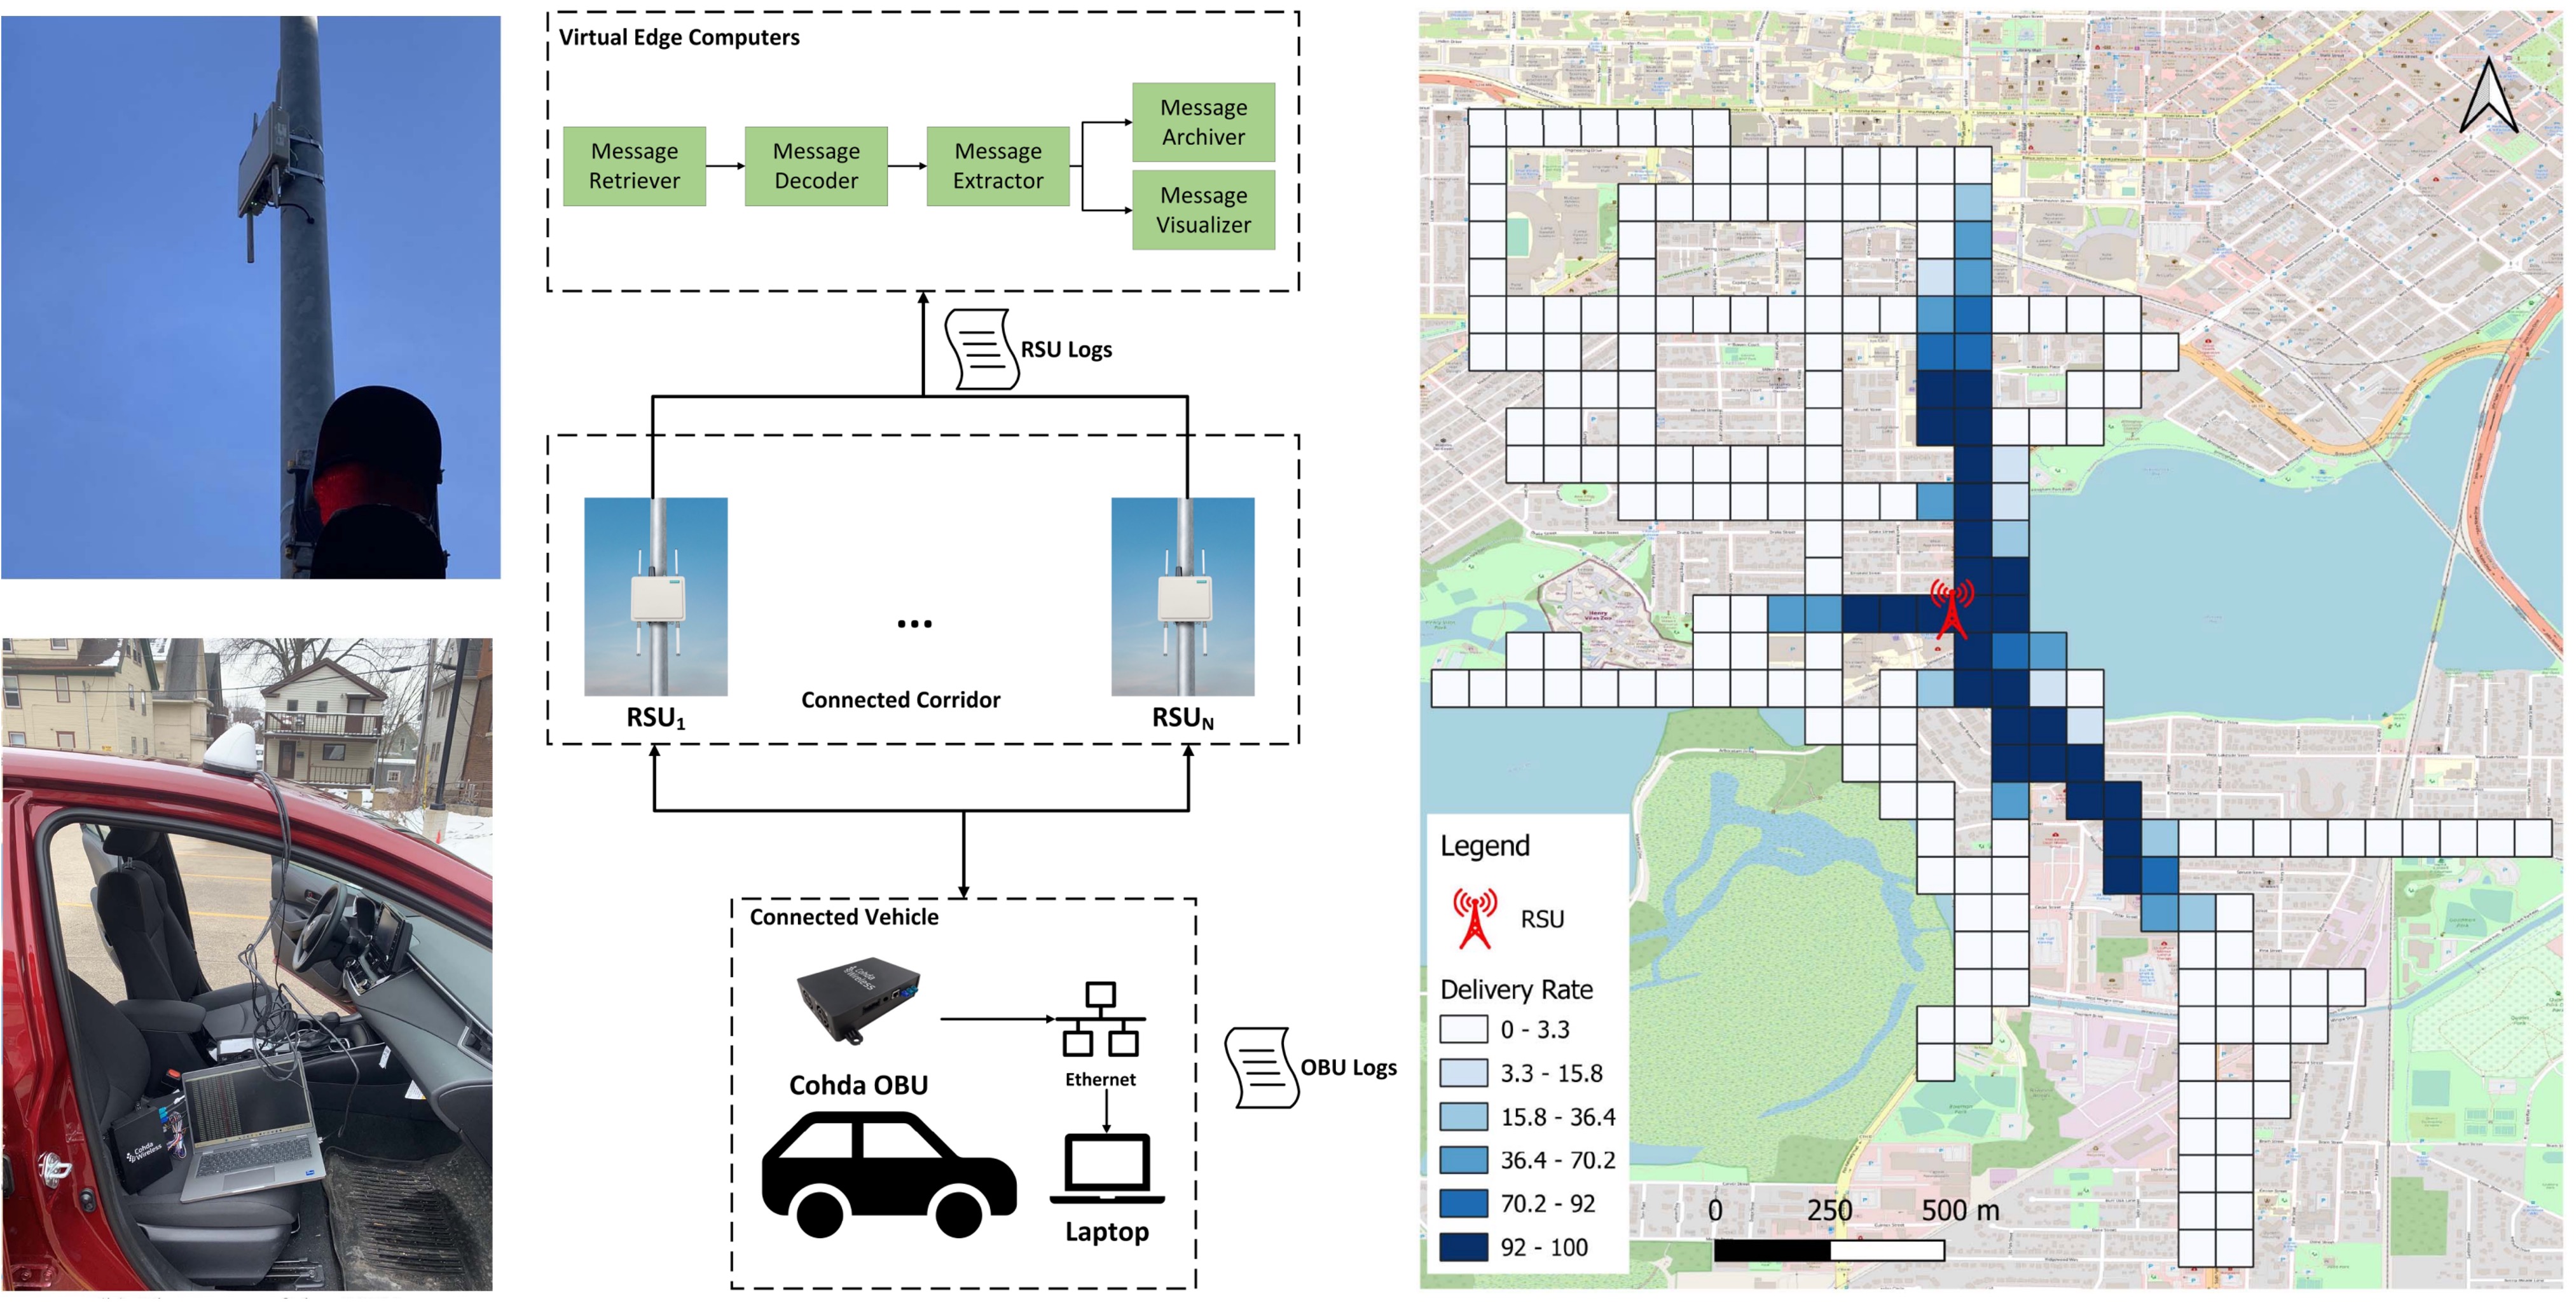
How Does C-V2X Perform in Urban Environments? Results From Real-World Experiments on Urban Arterials

Li, P., Wu, K., Cheng, Y., Parker, S. T., Noyce, D. A.

IEEE Transactions on Intelligent Vehicles · 2024